CORE SETUP
A core setup, defined by the task.
- Choose Thor-Duo / Quad / Hex by field of view and sync needs
- Choose the UMI gripper or tactile data glove by manipulation task
- Capture workstations, storage and calibration tools sized to throughput


DATA COLLECTION
From egocentric demonstrations to contact and motion signals, we define the capture protocol, quality gates and delivery format for each task. We help teams build in-house capture capability, or run batch capture and data delivery as a project.
Talk to us about this solutionHuman demonstration capture · Enterprise data delivery · Proprietary datasets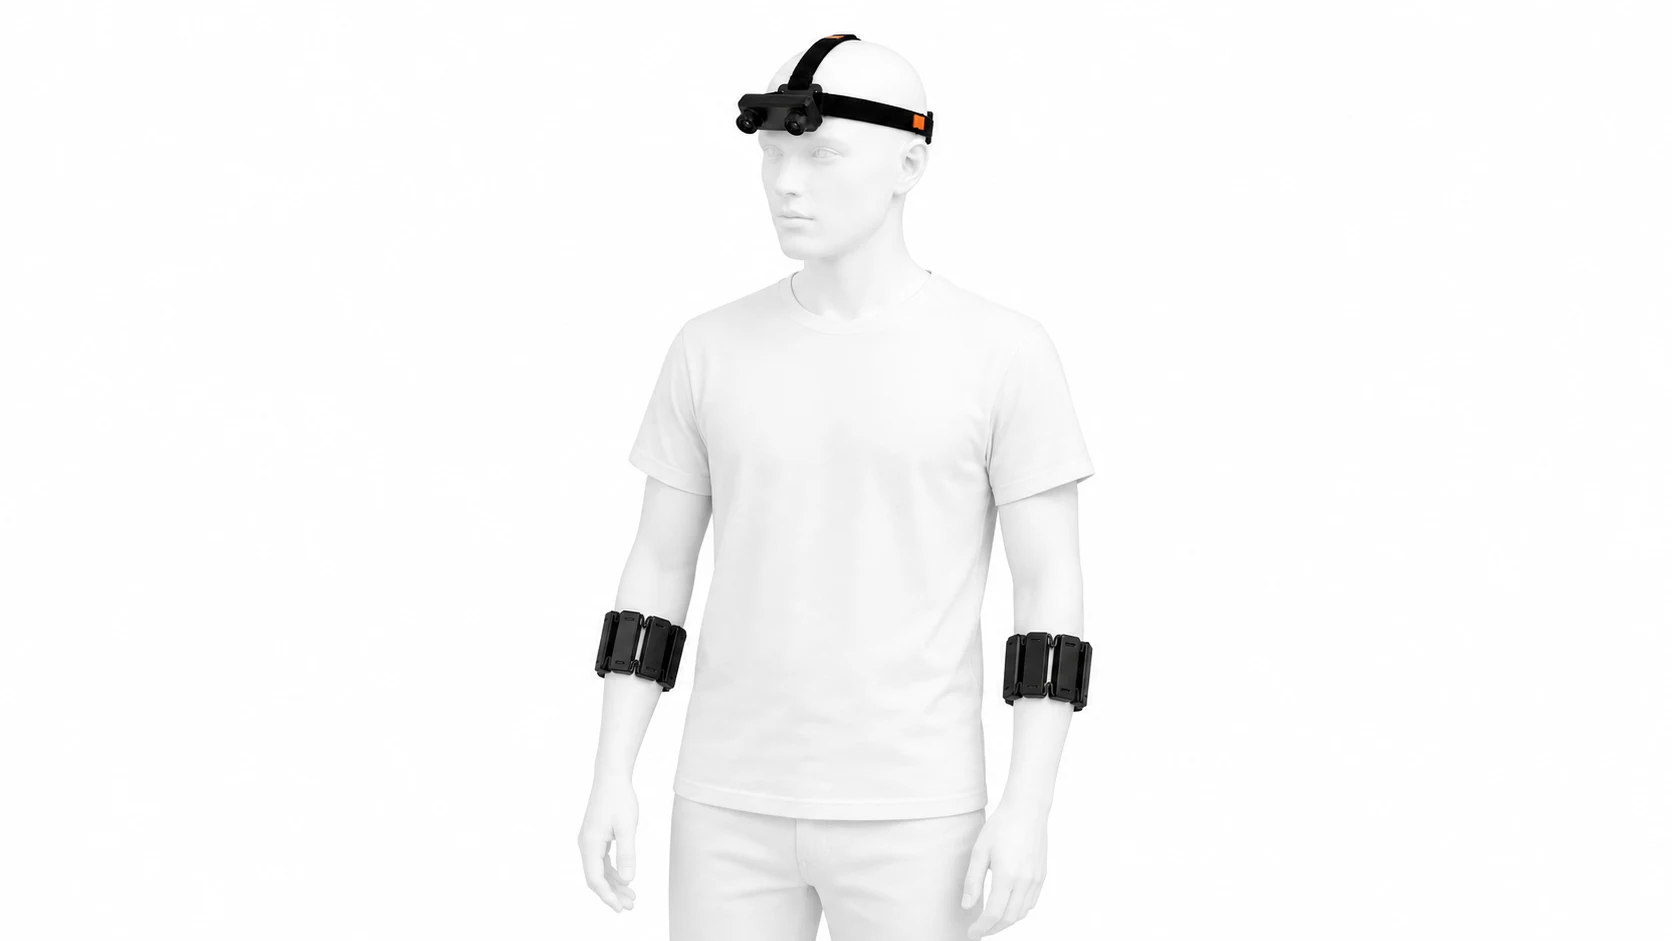
DEFINE YOUR USE CASE
CORE SETUP
OPTIONAL MODULES
WHAT YOU RECEIVE
Here's the delivery framework. Before kickoff, we agree item by item on scope, delivery format, ownership and acceptance criteria.
Task definitions, action segmentation, scene variables, device and calibration versions, and failure-case rules.
Raw recordings, timestamps, calibration files and task metadata; annotations and estimates stored separately.
Per-batch completeness, dropped frames, time offsets, task coverage and spot-check conclusions.
Version numbers, file lists, checksums, field dictionaries, scope of use and records of how problem episodes were handled.
Accept a small pilot batch before scaling up. Volume is counted as agreed valid episodes, valid duration or completed-task records, never as raw recording time.
CONFIGURE YOUR SYSTEM
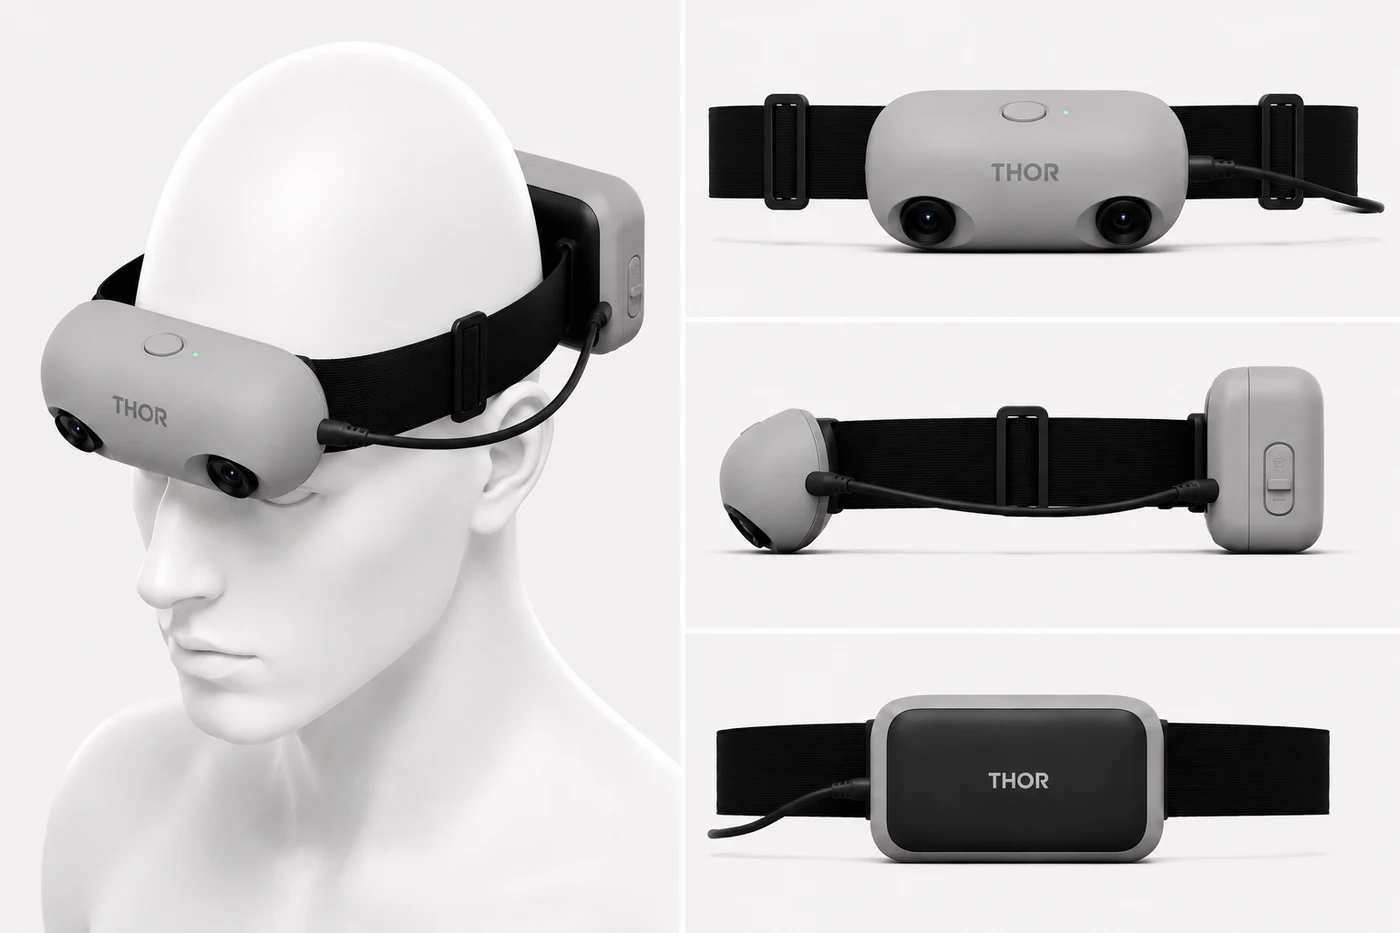 2 cameras + IMU
Stereo visual-inertial capture device
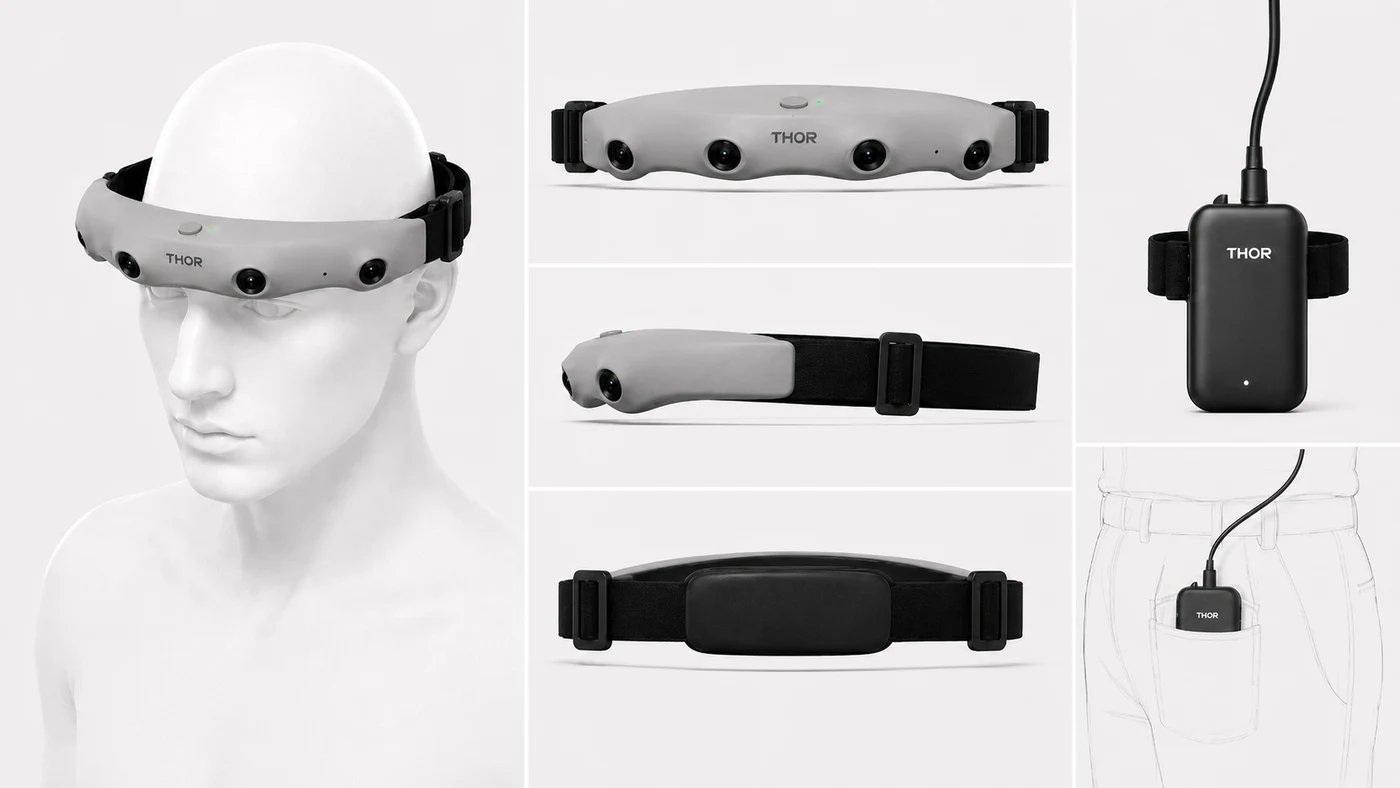 4 cameras + IMU
Quad-camera visual-inertial capture device
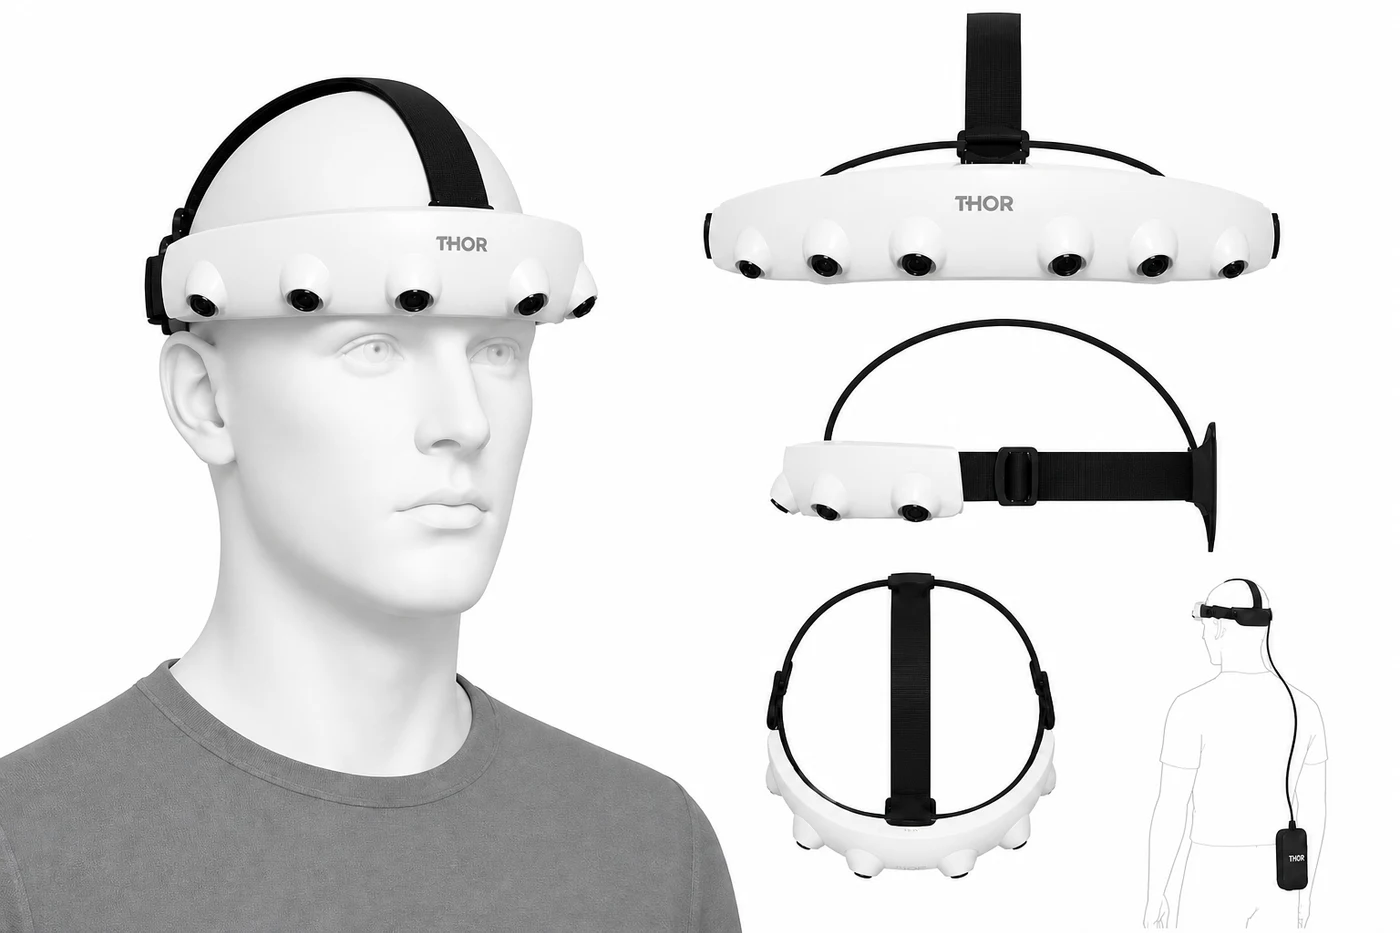 6 cameras + IMU
Six-camera visual-inertial capture device
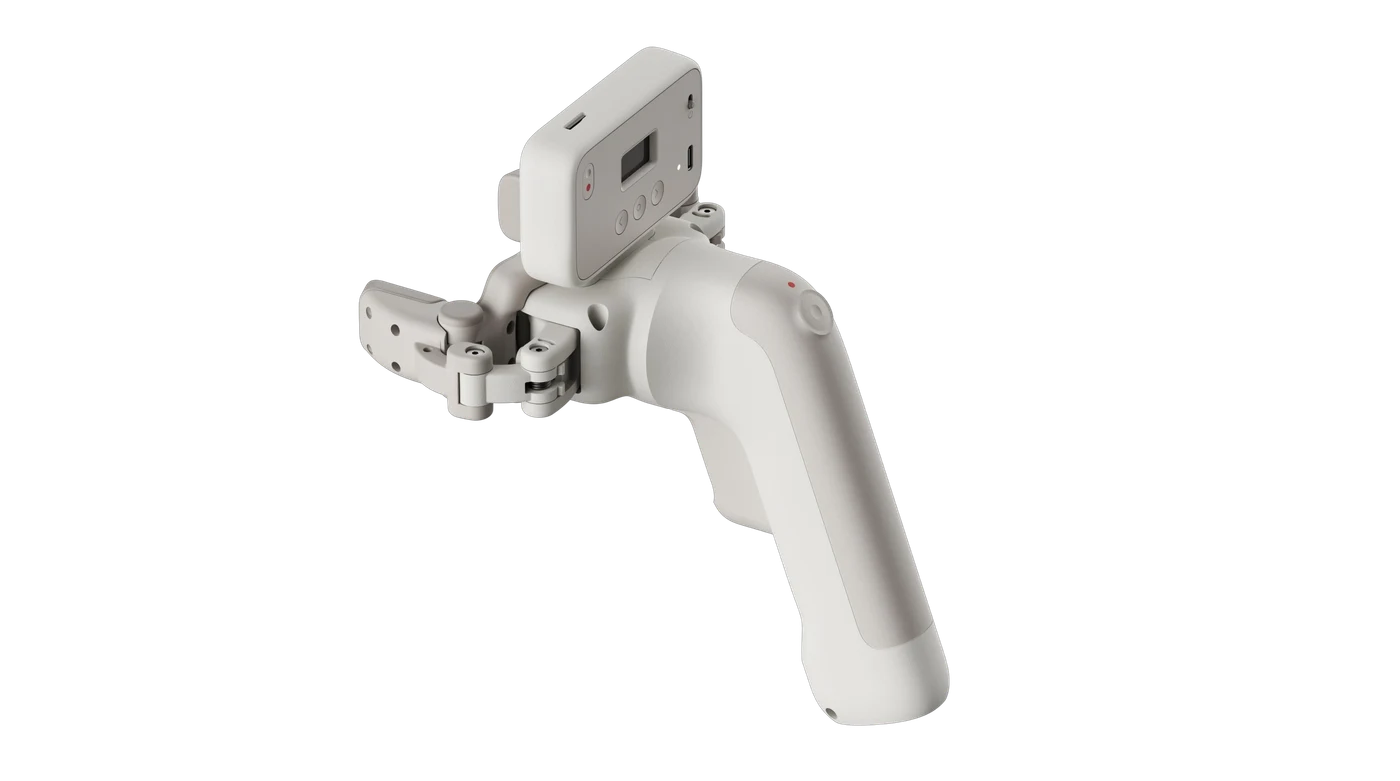 UMI Gripper
Handheld manipulation demonstration kit
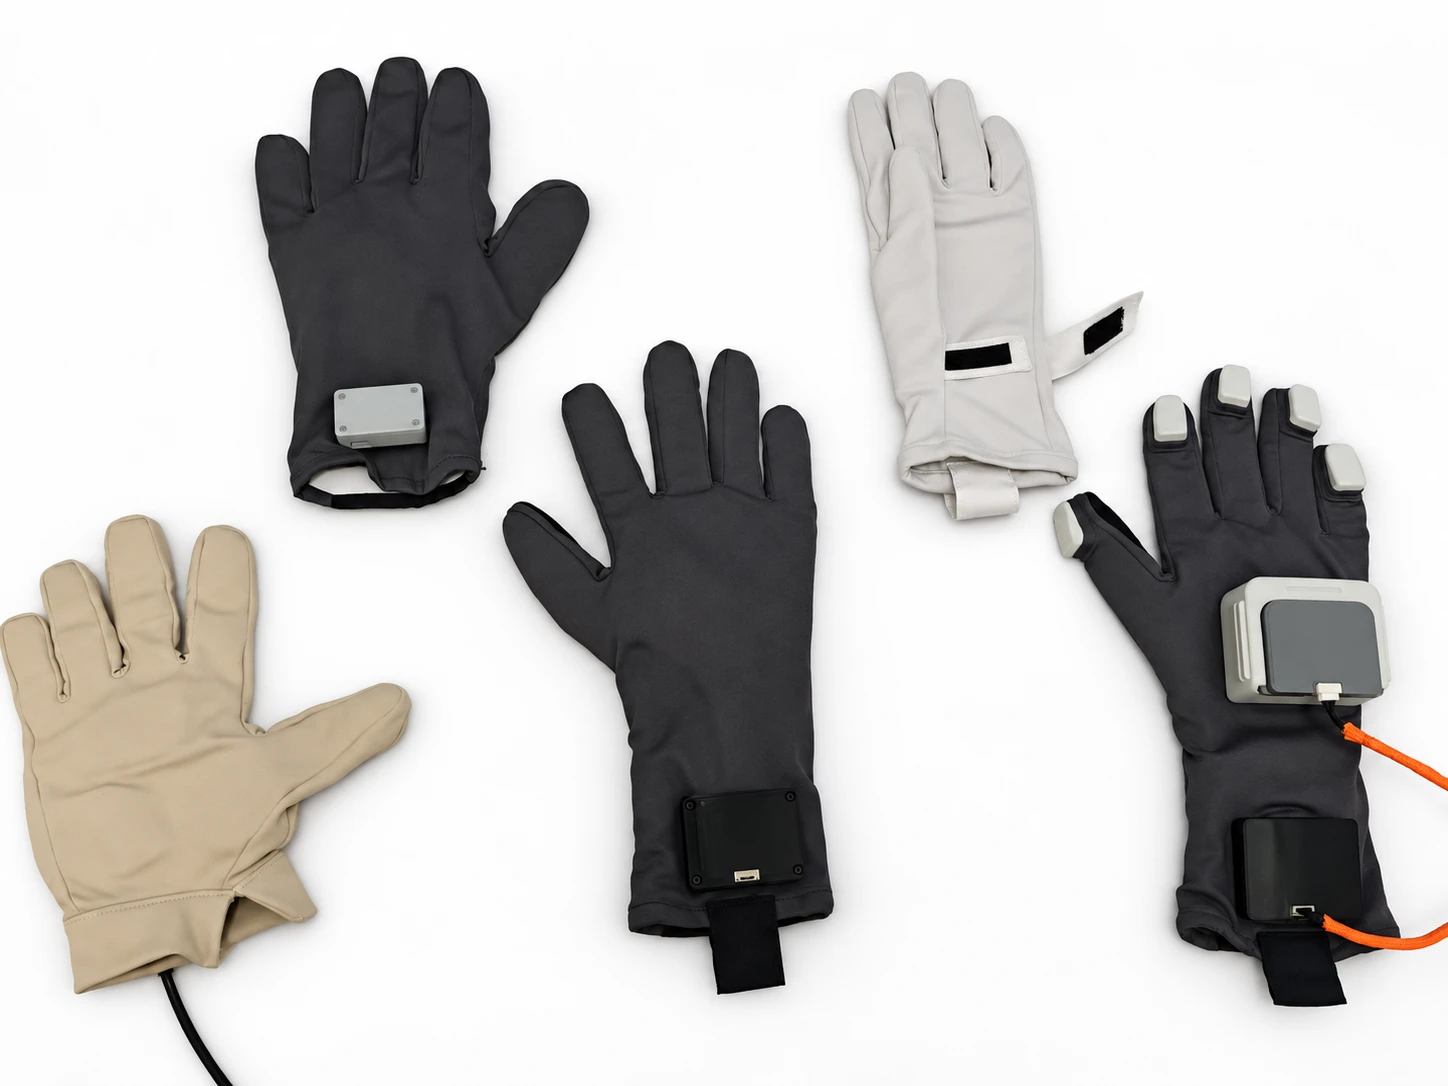 Tactile Data Glove
Tactile mapping with electromagnetic tracking
Ego + two armbandsMuscle-deformation and inertial capture armband
START WITH YOUR TASK
From device selection to data and training workflows, we'll help you find the right place to start.