Solutions / Multimodal Research Platform

MULTIMODAL RESEARCH

Multimodal Research Platform

Prove what each signal is worth.

Vision, touch, hand pose, FMG + IMU and robot state go into one experimental protocol. With unified timing and data versions, ablation studies show whether a new modality really improves robot manipulation.

Talk to us about this solutionMultimodal research · Dexterous manipulation · Joint data and model R&D
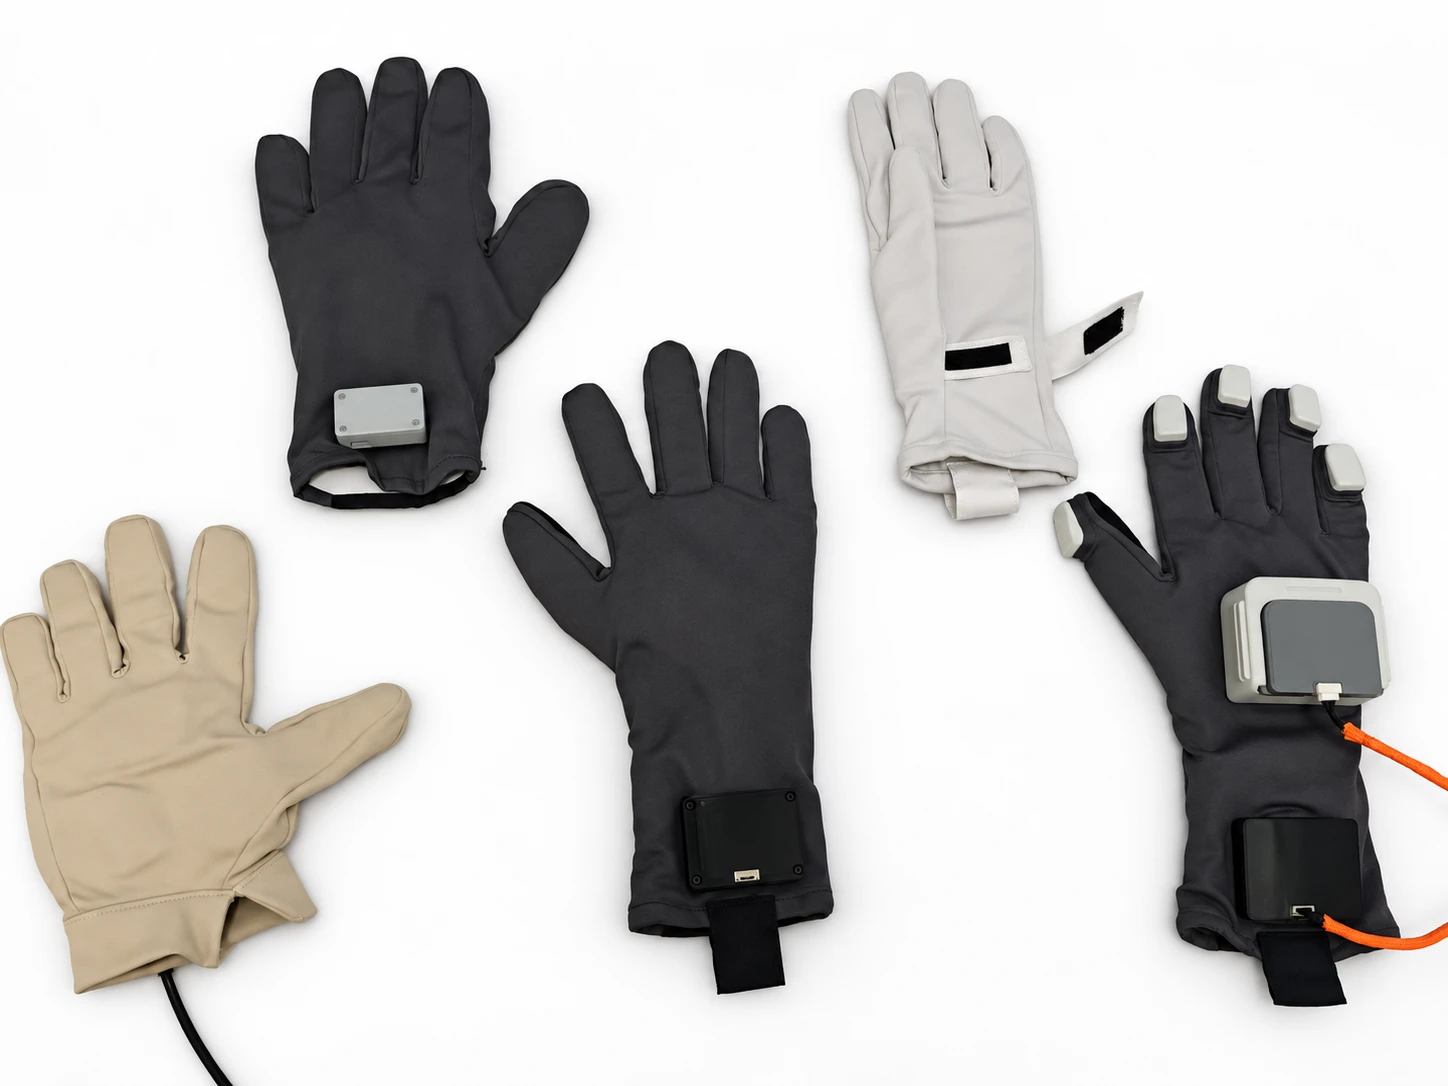
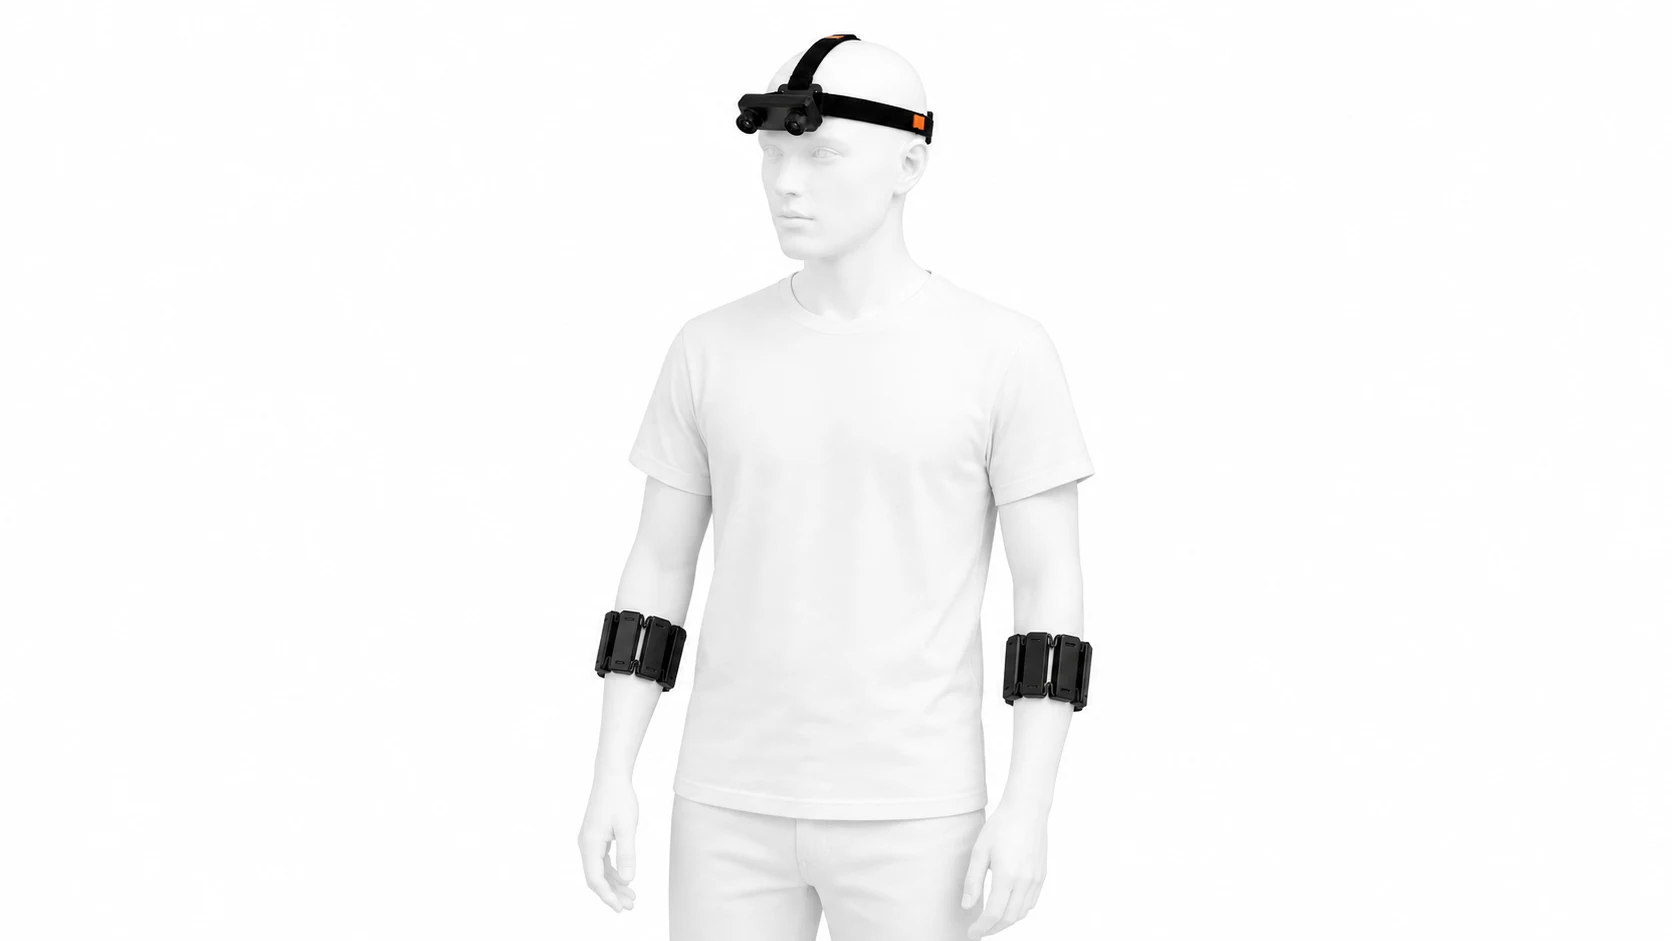
Tactile data glove; accessories confirmed per configuration

DEFINE YOUR USE CASE

Who it's for and how it's configured

Manipulation learning that fuses vision and touchMapping human demonstrations to robot actionsCross-participant comparisons of FMG, IMU and vision

CORE SETUP

A core setup, defined by the task.

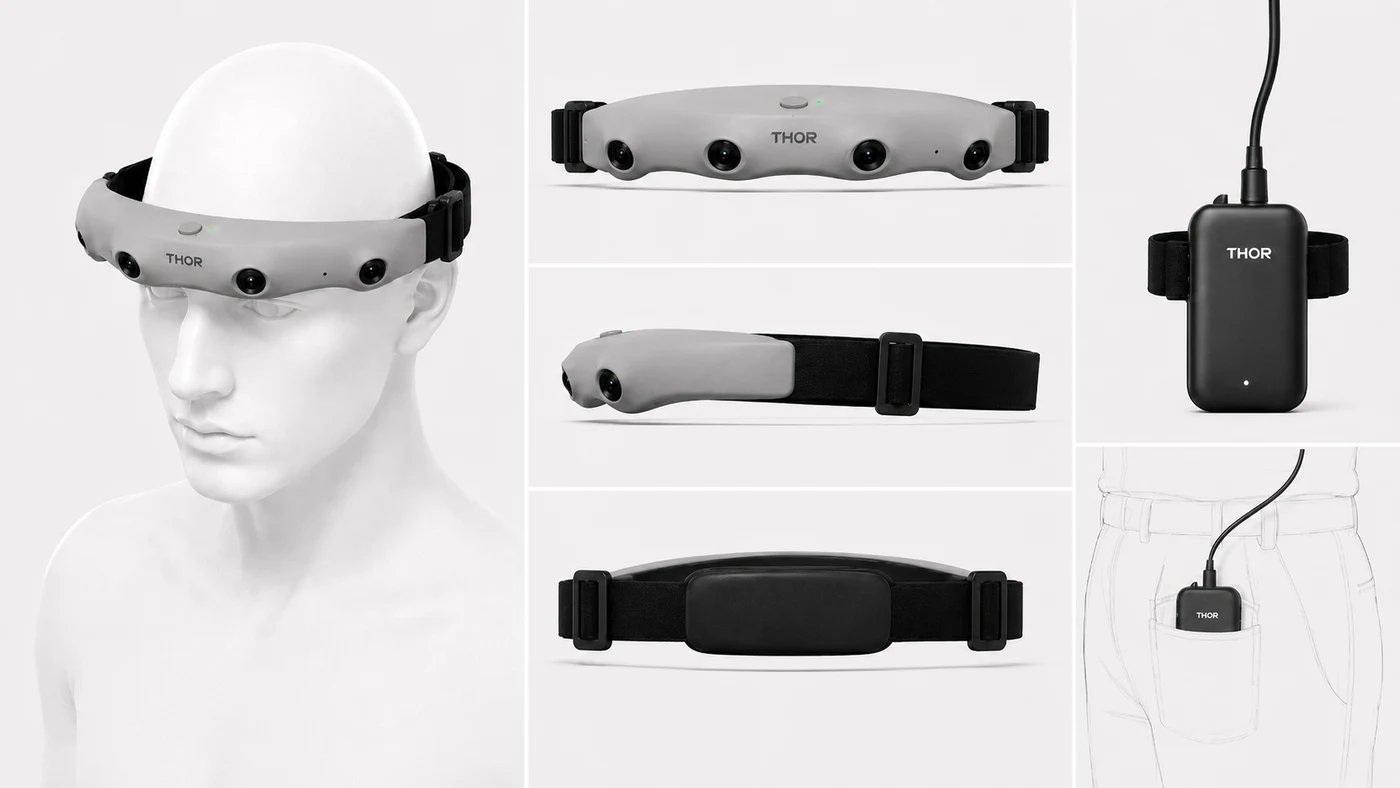
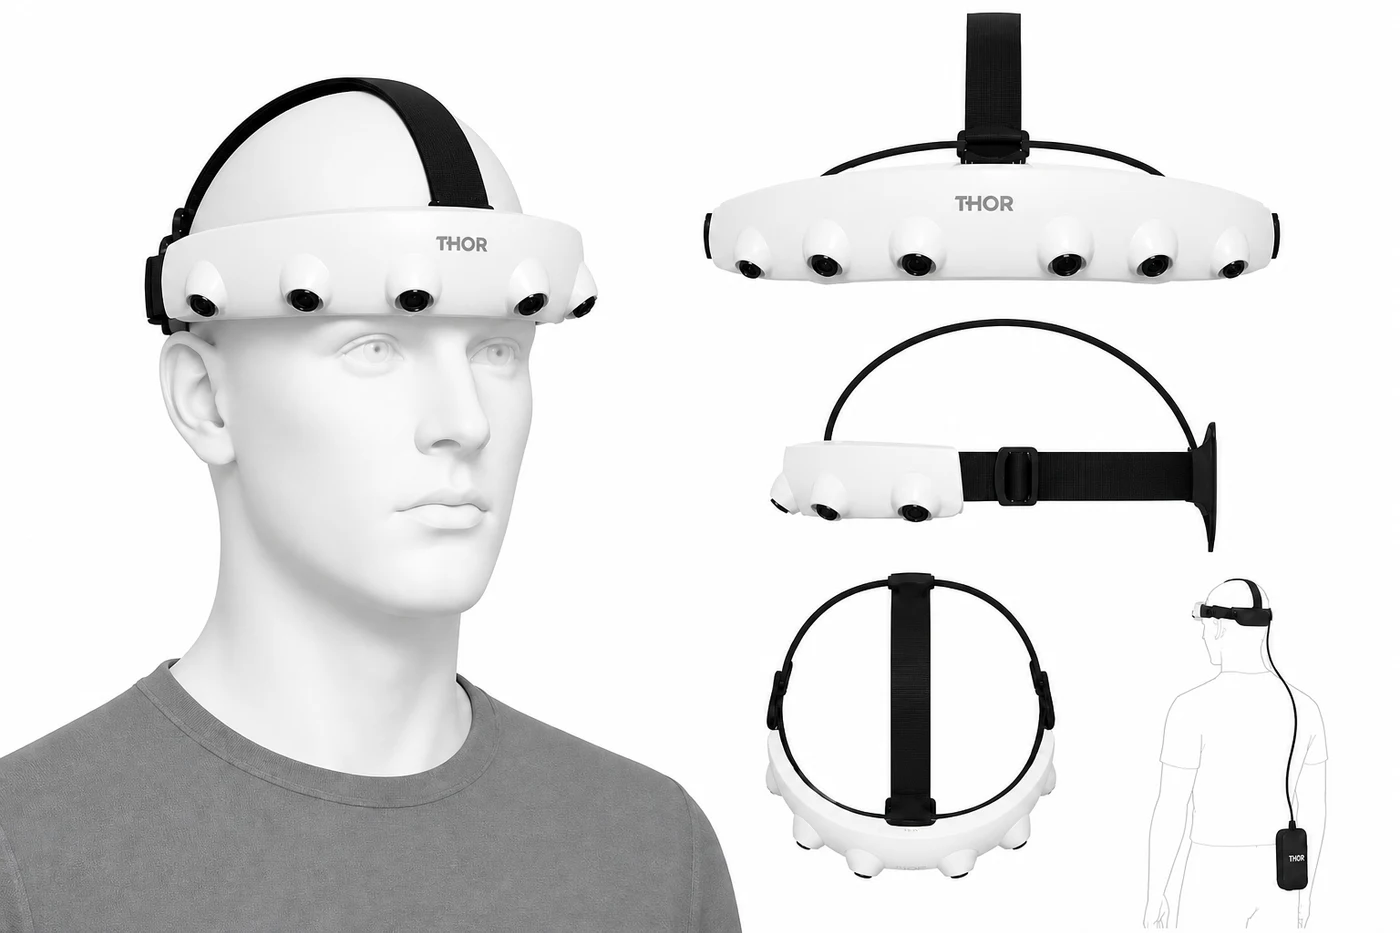
  • Select only the modalities your hypothesis needs, rather than stacking every sensor
  • Time sync, coordinate calibration and data-stream linkage protocol
  • Data version management and unified training and evaluation splits

OPTIONAL MODULES

Add what you need. Nothing is bundled by default.

  • Independent force or pose reference sensors for calibration and evaluation
  • Real-robot logs, failure clips and corrective re-demonstrations
  • Adaptation to third-party model APIs, offline algorithms and your own compute cluster

WHAT YOU RECEIVE

More than equipment.

Here's the delivery framework. Before kickoff, we agree item by item on scope, delivery format, ownership and acceptance criteria.

01

Sync and calibration package

Clocks, sampling rates, coordinate frames, extrinsics and alignment method for each device, with reported error.

02

Layered dataset

Raw observations, algorithm estimates, human annotations and robot action labels clearly separated.

03

Ablation studies

Compare a vision baseline, a single added modality and joint inputs on the same task and data split.

04

Research report

Gains, failure conditions and performance across people, dates and scenes, feeding the next round of capture.


How we define done

Sync and data integrity are confirmed before offline metrics are accepted. Any claim of "improved robot manipulation" must ultimately be validated in controlled real-robot comparisons; a gesture-recognition score is not a manipulation success rate.

CONFIGURE YOUR SYSTEM

Products that work together

START WITH YOUR TASK

Tell us about your research task.

From device selection to data and training workflows, we'll help you find the right place to start.

Contact us