Solutions / Robot Learning Workstation

ROBOT LEARNING

Robot Learning Workstation

Train and validate on one well-defined task.

For university and corporate R&D teams, we bring together robots, teleoperation, vision and compute. From recording demonstrations to training baselines and evaluating on real robots, we build reproducible experiments around a clear task, rather than just shipping hardware.

Talk to us about this solutionUniversity labs · Corporate R&D teams · Robot developers
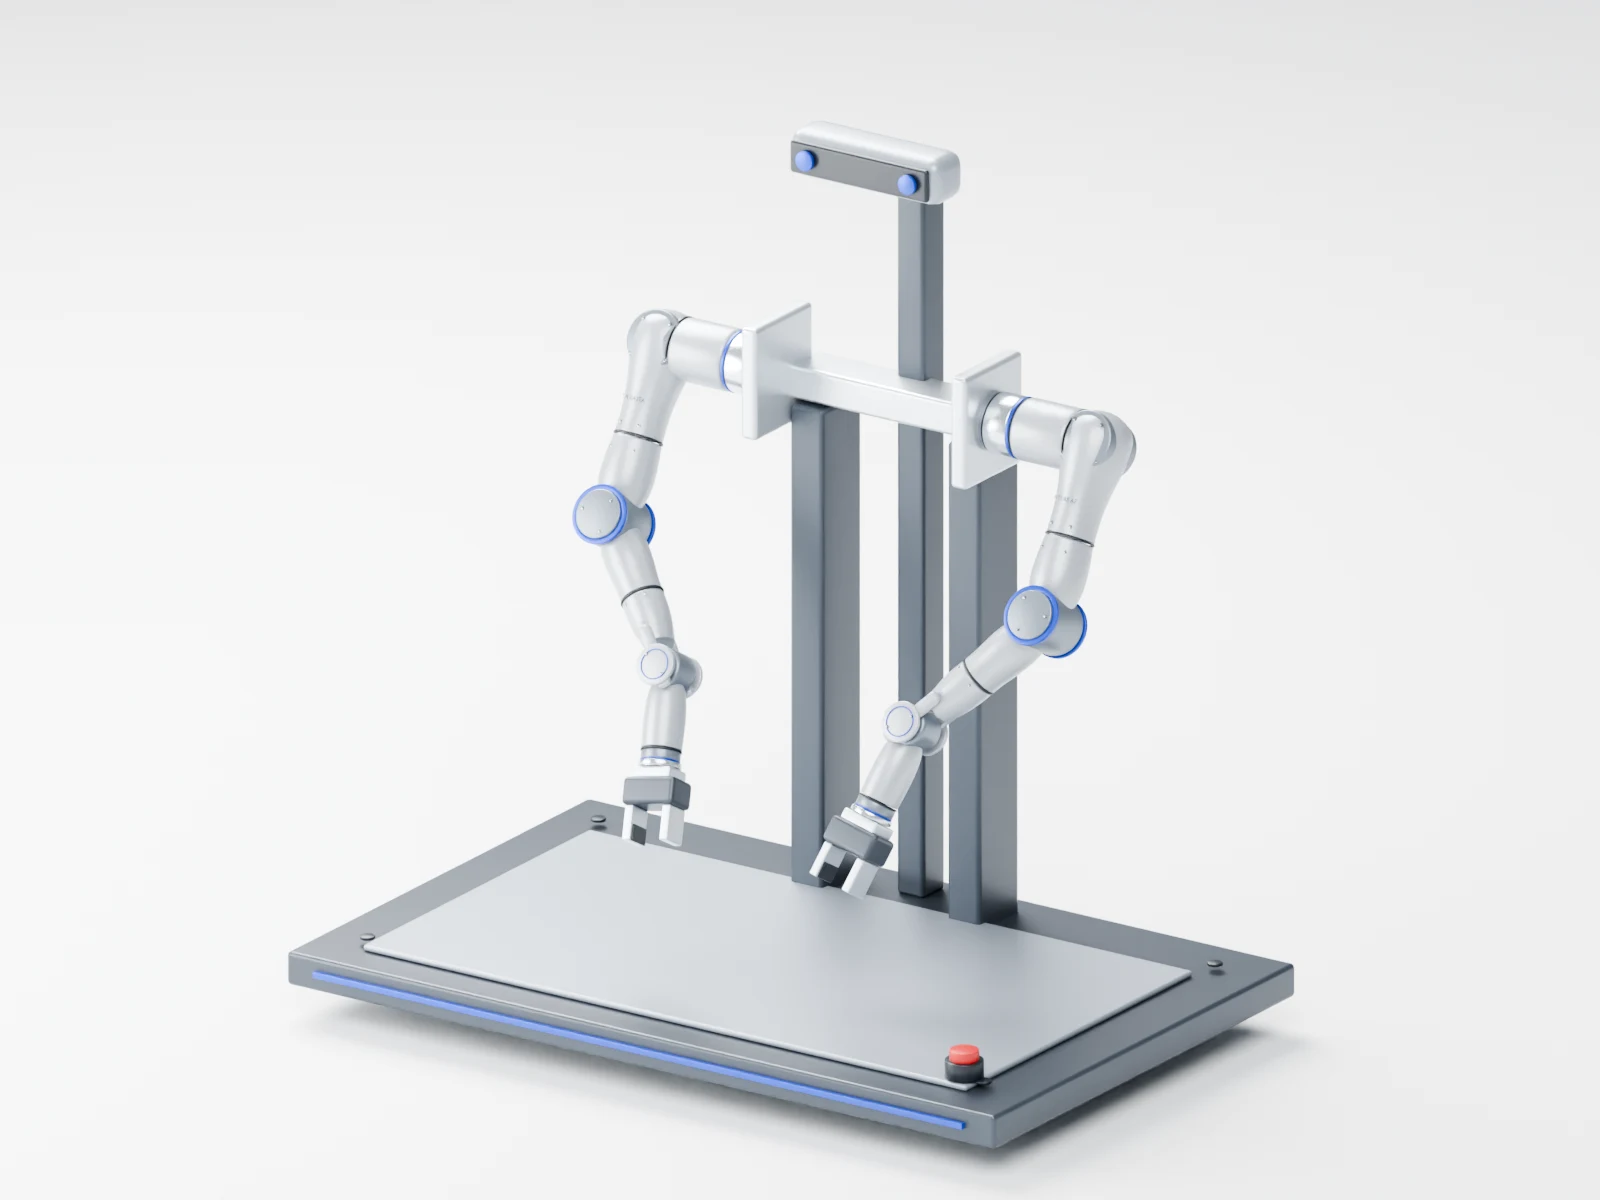
A7 dual-arm desktop workstation

DEFINE YOUR USE CASE

Who it's for and how it's configured

Single-arm grasping, pick-and-place and basic manipulation researchDual-arm coordination and teleoperated demonstrationsMobile manipulation and cross-scene task validation

CORE SETUP

A core setup, defined by the task.

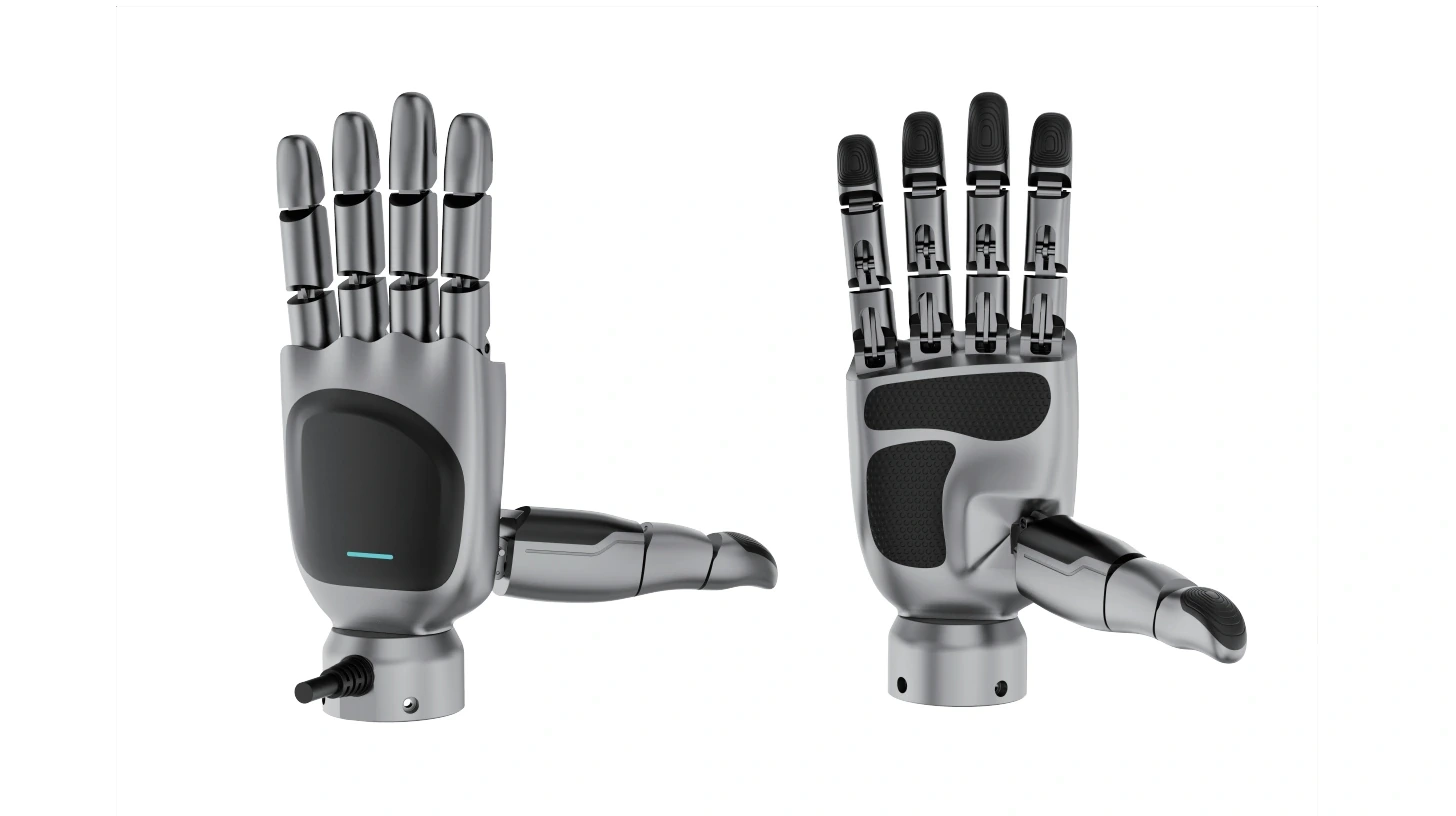
  • Atlas R1 / A7 / D selected by workspace and task, with the optional eHand-6 dexterous hand as end effector
  • Cameras, end effectors, fixtures and safety components
  • Capture and inference workstations, software environment and experiment logging conventions

OPTIONAL MODULES

Add what you need. Nothing is bundled by default.

  • Tactile end effectors, human-side capture devices and multimodal pairing
  • Cloud GPU training resources and model adaptation services
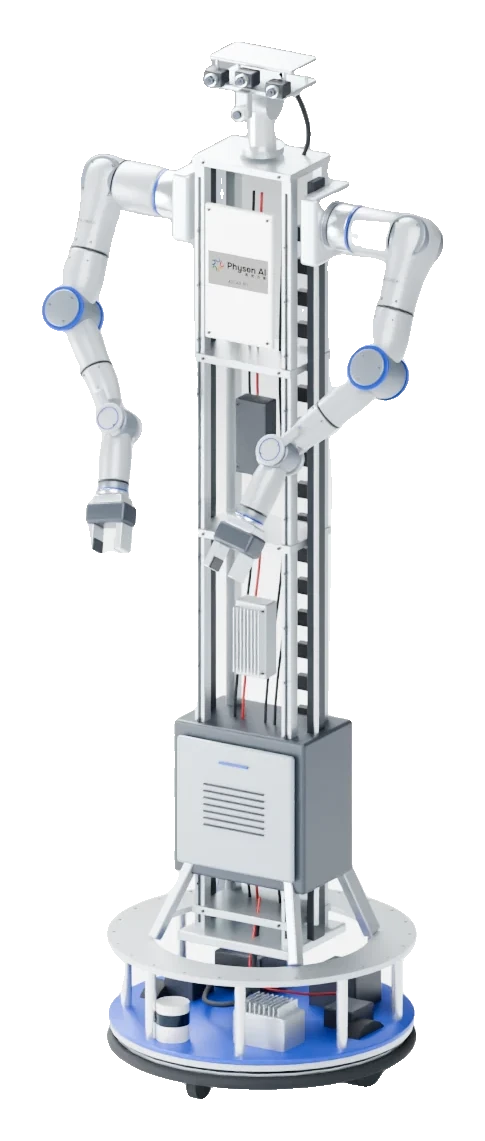
  • Optional Atlas R1 base, lift, vision and teleoperation modules

WHAT YOU RECEIVE

More than equipment.

Here's the delivery framework. Before kickoff, we agree item by item on scope, delivery format, ownership and acceptance criteria.

01

Integration list

Robot, cameras, end effector, workstation and software versions, plus interfaces and responsibilities for each component.

02

Task data

Teleoperation workflow, recorded fields, calibration records and demonstration data within the agreed scope.

03

Reproducible baseline

When included, we deliver training configs, data versions, runtime environment, model weights and license notes.

04

Evaluation records

Fixed test conditions, task success rate, completion time, human intervention and failure categories, with raw logs attached.

How we define done

Devices and safety functions, data recording, model reproduction and real-robot tasks are accepted separately. Success rates are tied to task, objects, initial state and number of trials, and are not a guarantee for arbitrary environments.


CONFIGURE YOUR SYSTEM

Products that work together

START WITH YOUR TASK

Tell us about your research task.

From device selection to data and training workflows, we'll help you find the right place to start.

Contact us