

THE PRODUCT COLLECTION
Every device has a role.
Data makes them a system.
Atlas arms and dexterous hands execute; Thor, UMI, gloves and armbands record human demonstrations. Pick the modalities each task needs, then run training and validation through the Data Engine.
ATLAS / ROBOT LEARNING
Atlas Robot Series
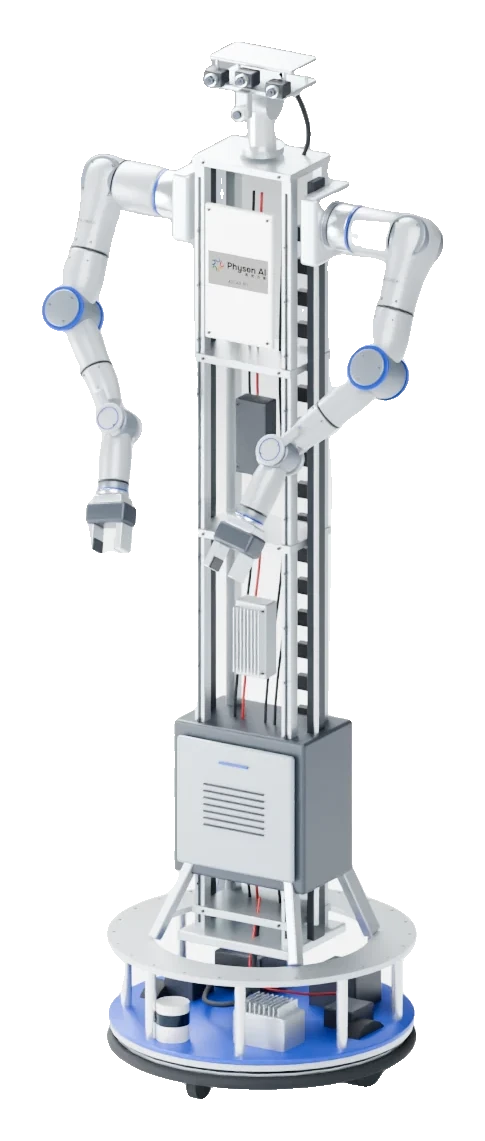
The R1 modular platform, the A7 7-axis arm and the D desktop dual-arm platform cover fixed workstations, mobile manipulation and teleoperation research.
MODULAR / ROBOT LEARNING
Modular platformAtlas R1
A7 Dual-Arm Modular Research Platform
DESKTOP / A7 BIMANUAL LEARNING
Configured per projectAtlas D
A7 Desktop Dual-Arm Learning Platform
7-AXIS / RESEARCH MANIPULATOR
Configured per projectAtlas A7
Lightweight 7-Axis Research ArmDEXTEROUS HAND / END EFFECTORS
Dexterous Hand Series
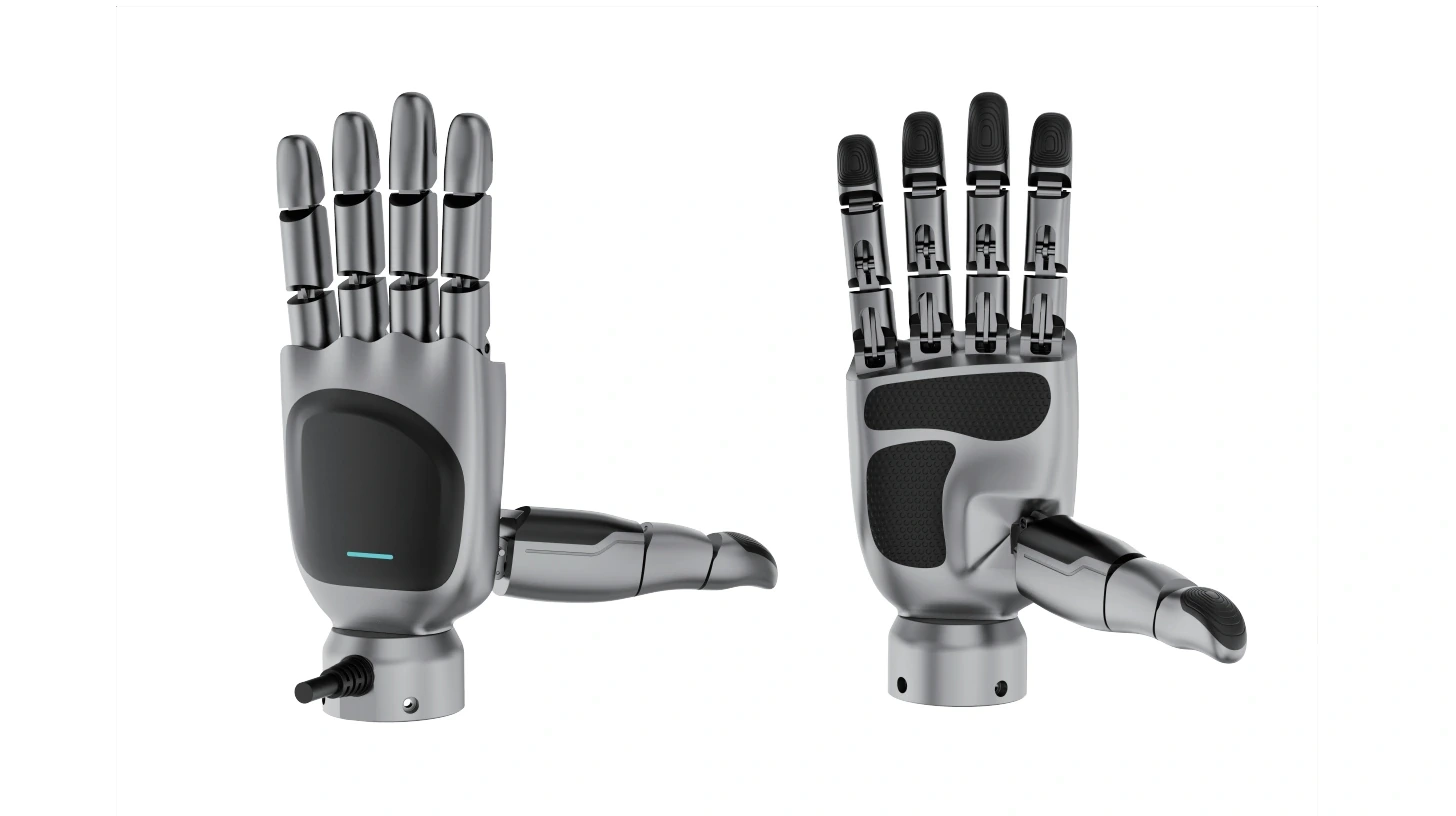
eHand-6 comes in left- and right-hand versions, with six control channels driving coordinated five-finger motion. It ties together arm execution, teleoperation mapping and manipulation data.
EGO THOR / VISION & INERTIAL
Ego Thor Series
Thor-Duo (2 cameras), Thor-Quad (4 cameras) and Thor-Hex (6 cameras) capture manipulation from the wearer's point of view.
Compare series configurations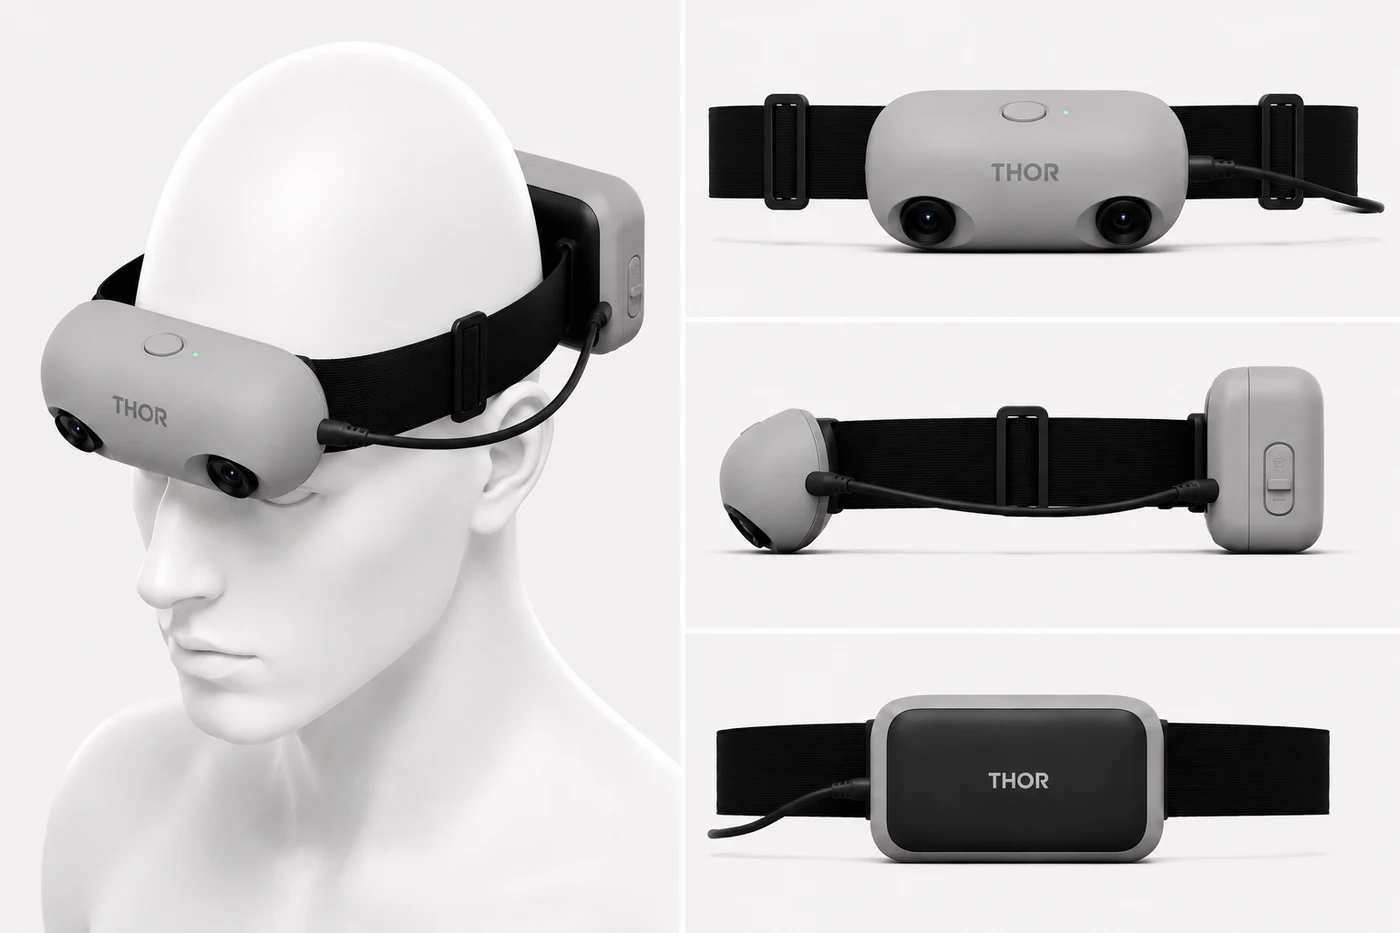 2 cameras + IMU
EGO THOR / 2 CAMERAS + IMU
Multiple configurationsThor-Duo
Stereo visual-inertial capture device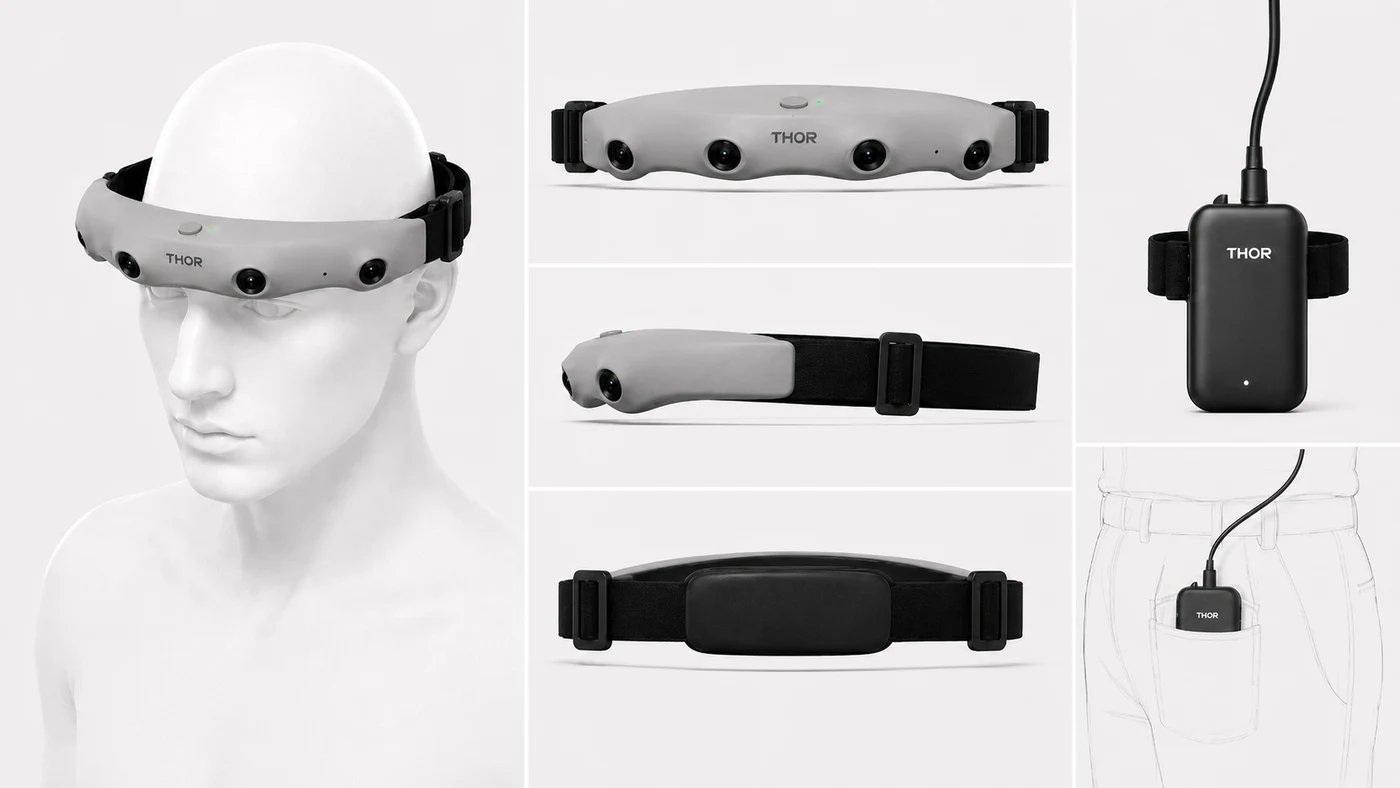 4 cameras + IMU
EGO THOR / 4 CAMERAS + IMU
Multiple configurationsThor-Quad
Quad-camera visual-inertial capture device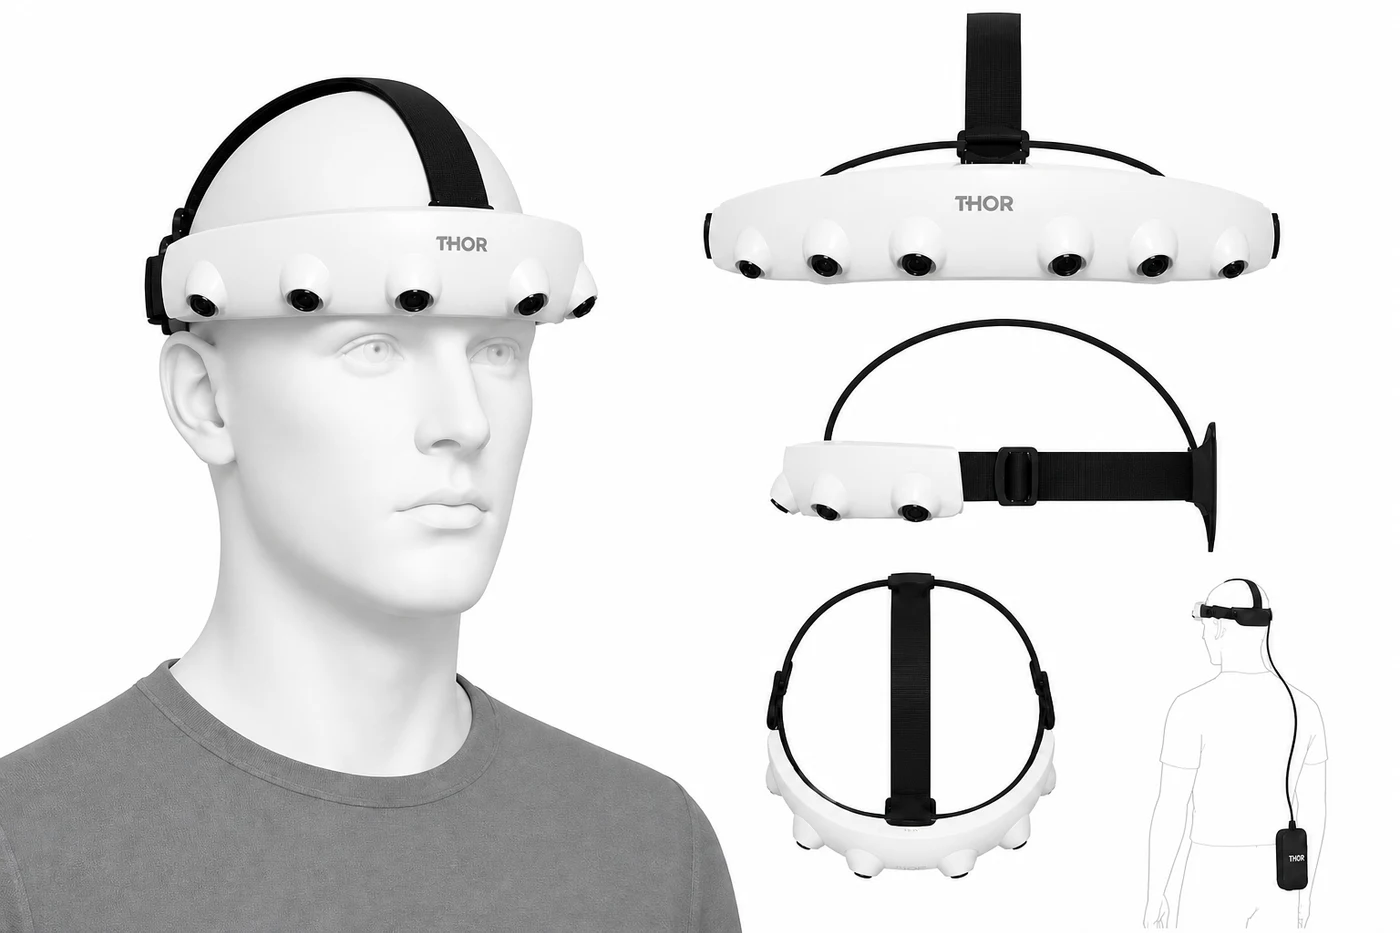 6 cameras + IMU
EGO THOR / 6 CAMERAS + IMU
Multiple configurationsThor-Hex
Six-camera visual-inertial capture deviceUMI & GLOVES / MANIPULATION
UMI / Glove Series
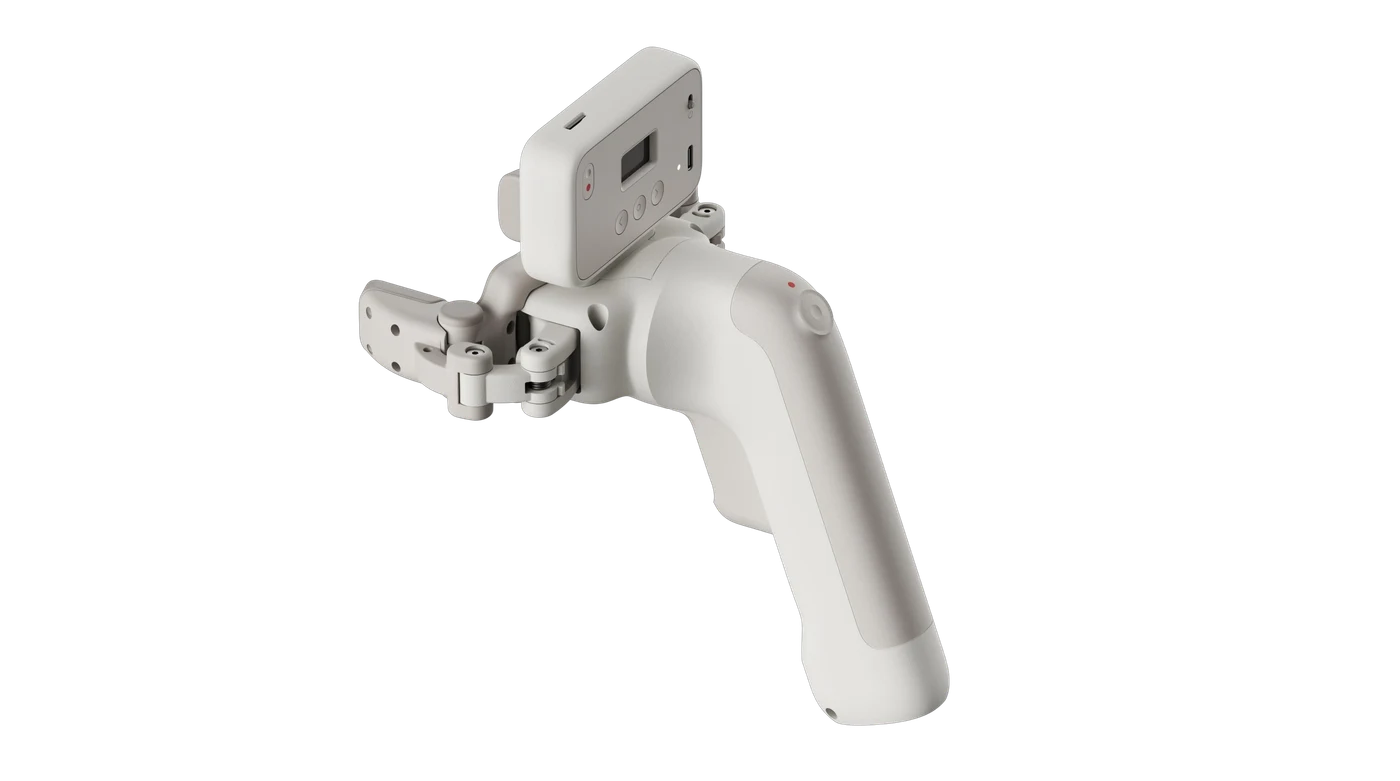
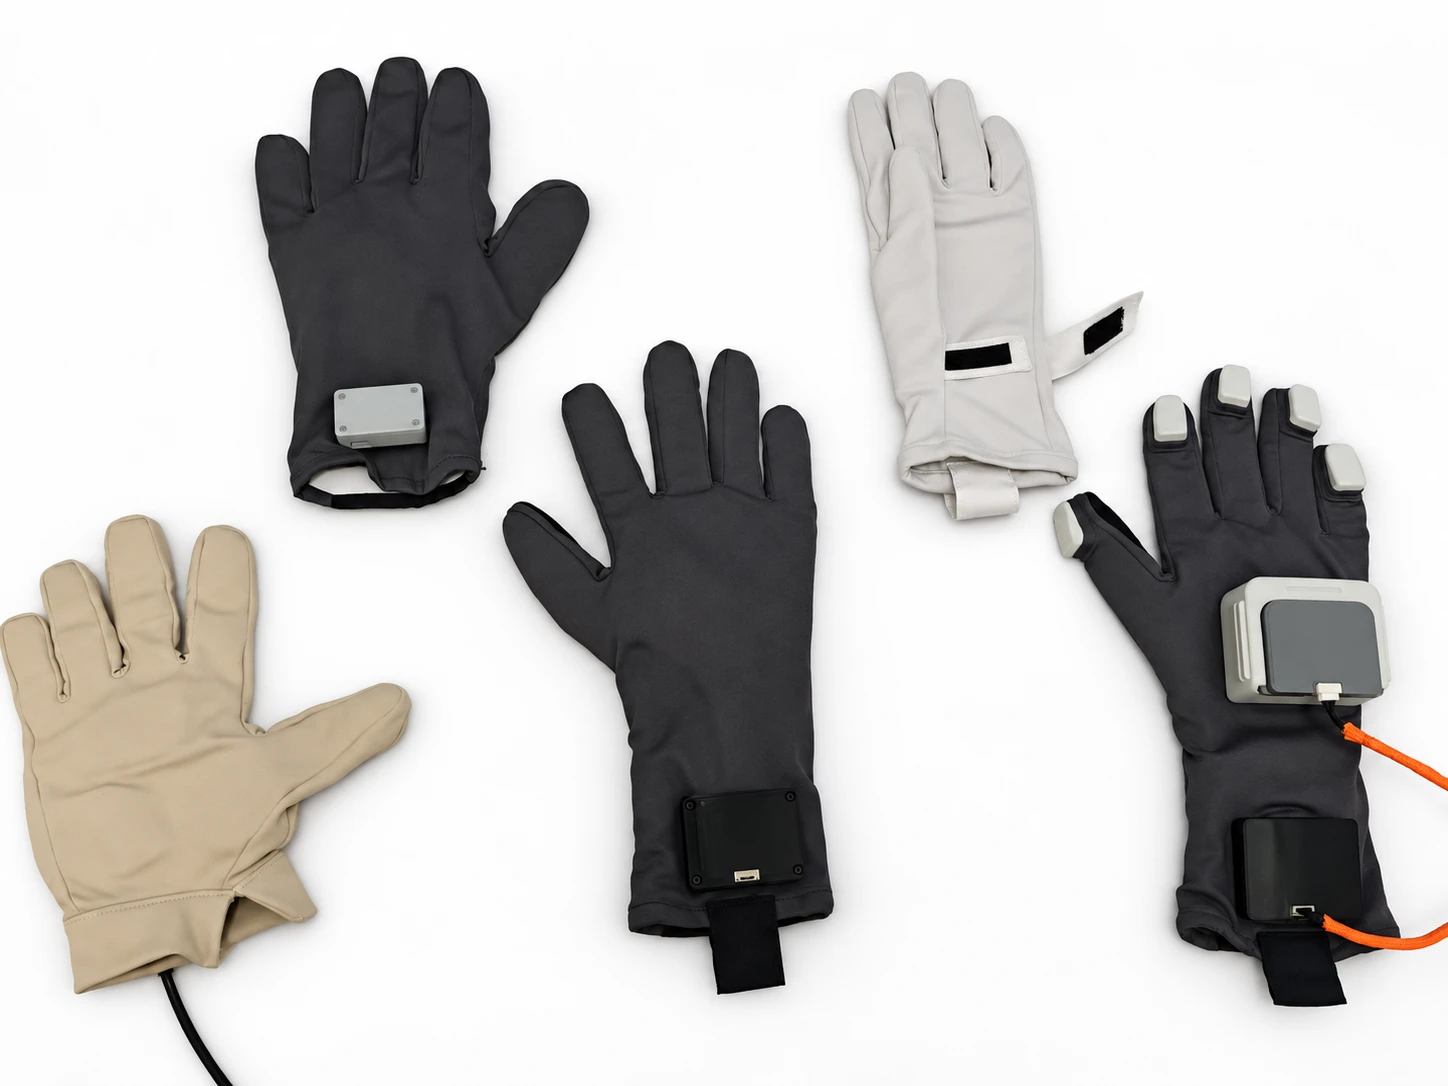
From handheld gripper demonstrations to tactile and electromagnetic pose tracking, capturing manipulation and contact together.
ARMBANDS / MUSCLE & MOTION
Armband SeriesComing Soon
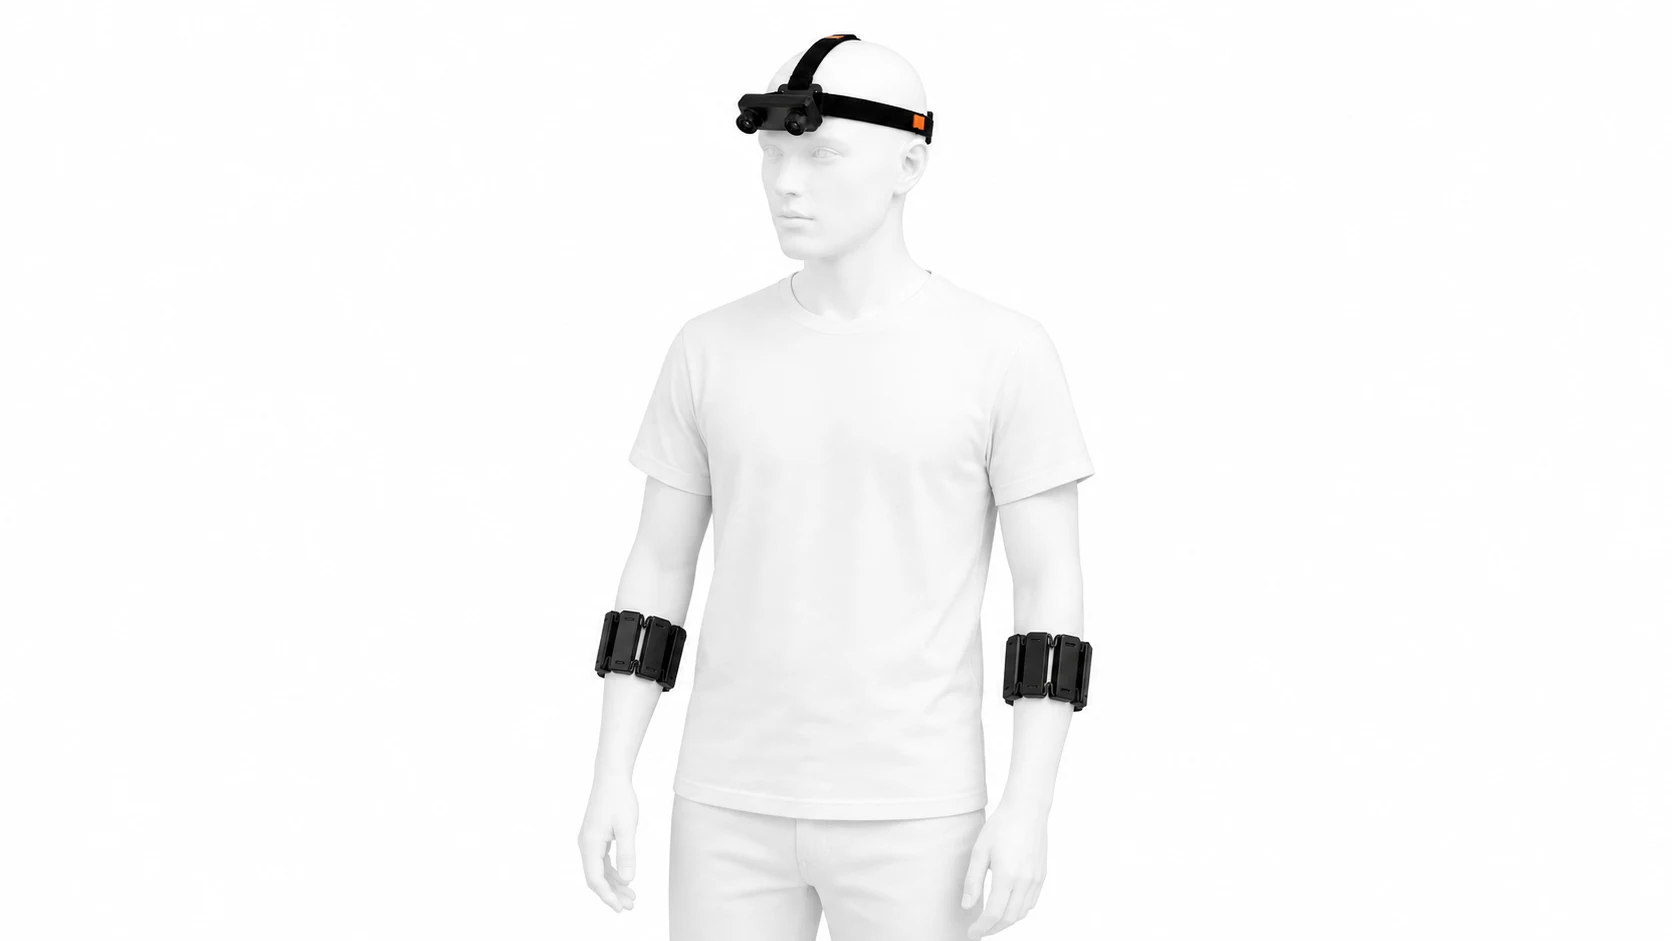
The FMG + IMU armband: how it's worn, how it's built and where it fits in multimodal capture research.
START WITH YOUR TASK
Tell us about your research task.
From device selection to data and training workflows, we'll help you find the right place to start.