One protocol, every site
Tasks, scene variables, devices and calibration are specified the same way at every capture site.


ROBOT LEARNING, CONNECTED.
Wearable capture, robot workstations and a data engine
that turn human demonstrations into robot training data.
University labs / Corporate R&D / Data capture teams
 DATA
Use the arrow keys or drag the cards to switch. Autoplay pauses on hover or focus.
THREE WAYS TO START
Capture a single task, stand up a robot lab or run multimodal research. Buy devices on their own, or get a complete system built around your goal.
THE LEARNING LOOP
Devices to data, models back to tasks.
Follow a single recording through the full research loop.
Failure attribution → targeted re-capture → next data version
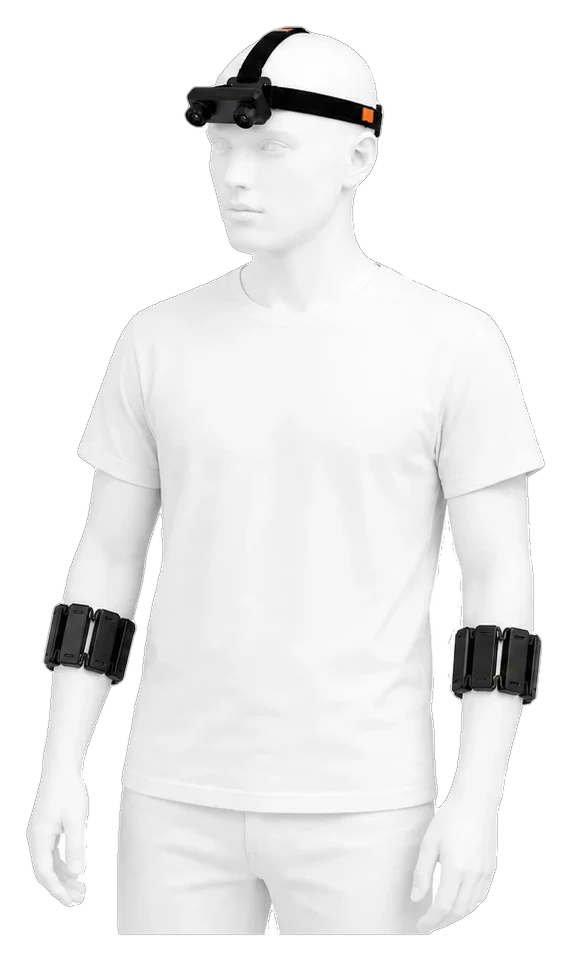
Capture egocentric video, demonstrations and contact signals in one shared task context. Pick Ego, UMI, gloves, armbands or real-robot capture to fit the scene.
Task definition / device records / raw dataEach stage is configured and validated per project.
BUILT FOR DATA OPERATIONS
Enterprises don't need more video. They need data that fits the task definition, passes QA, stays traceable and comes with clear usage rights.
See the data delivery processTasks, scene variables, devices and calibration are specified the same way at every capture site.
Define what counts as a valid episode, and keep rejection reasons, spot-check records and batch reports.
Versioned datasets with field dictionaries and access control, not scattered folders.
THE HARDWARE, CONNECTED
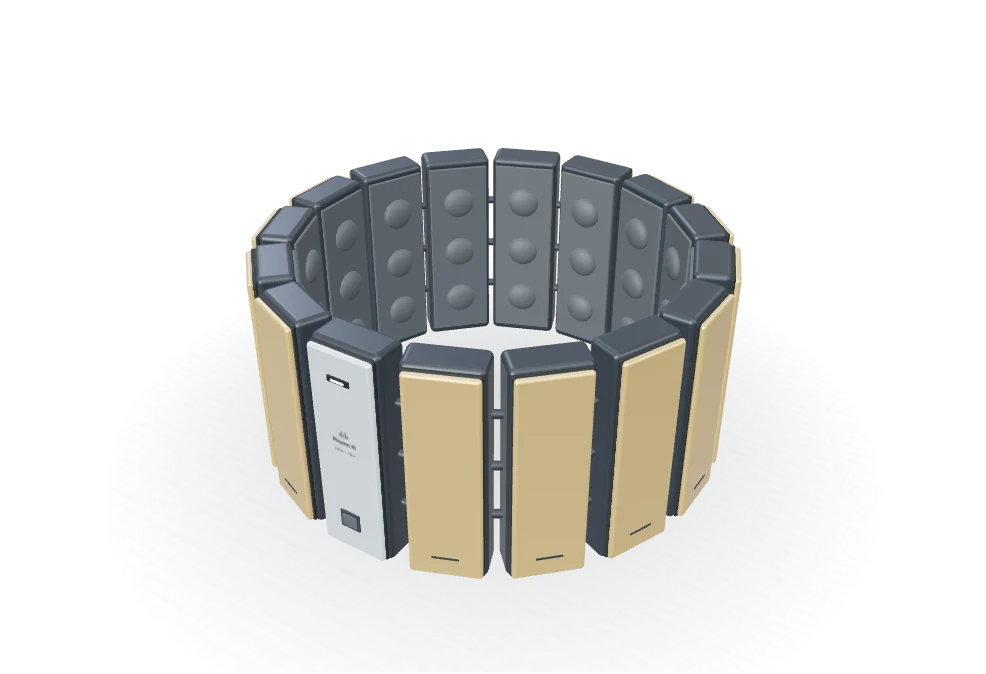
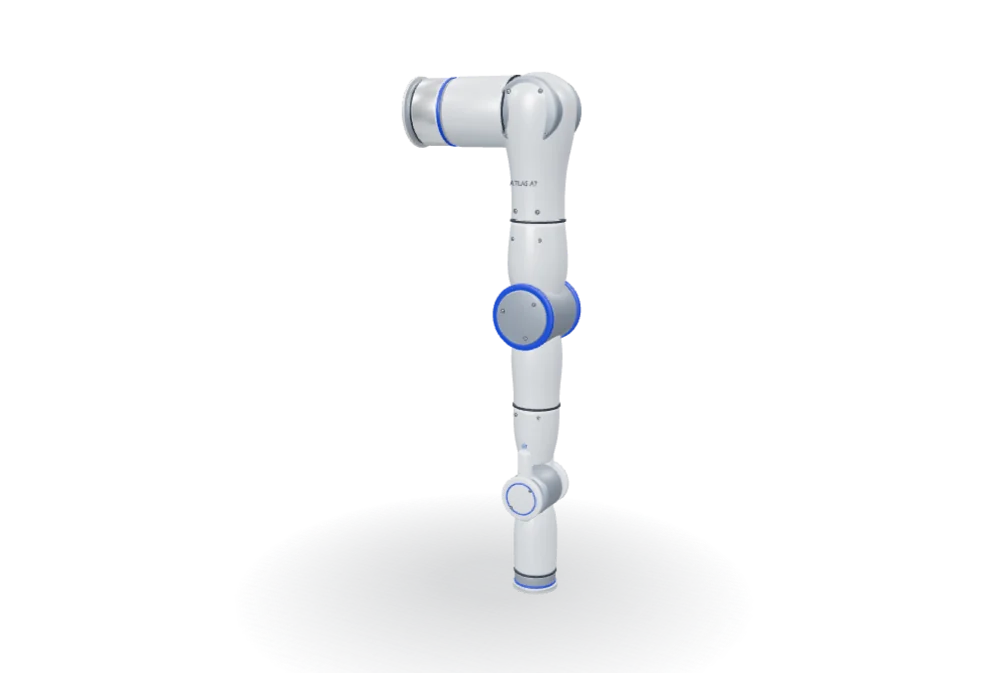
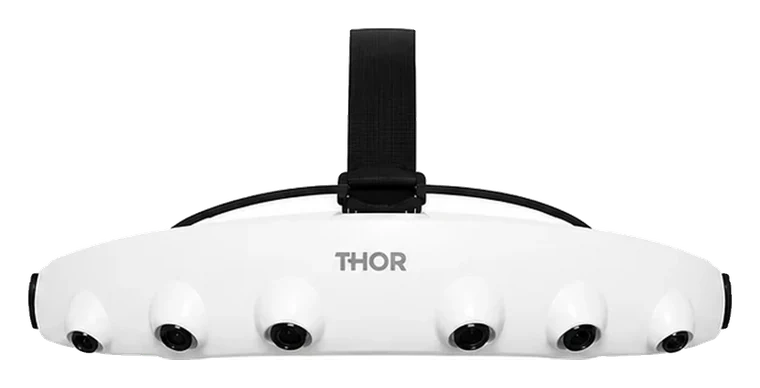
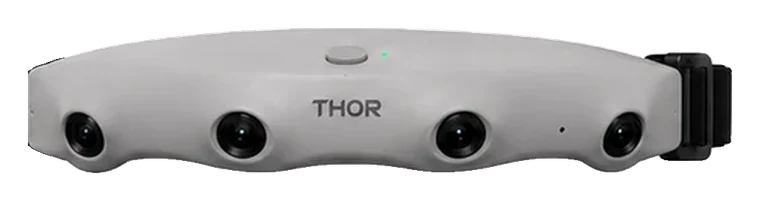
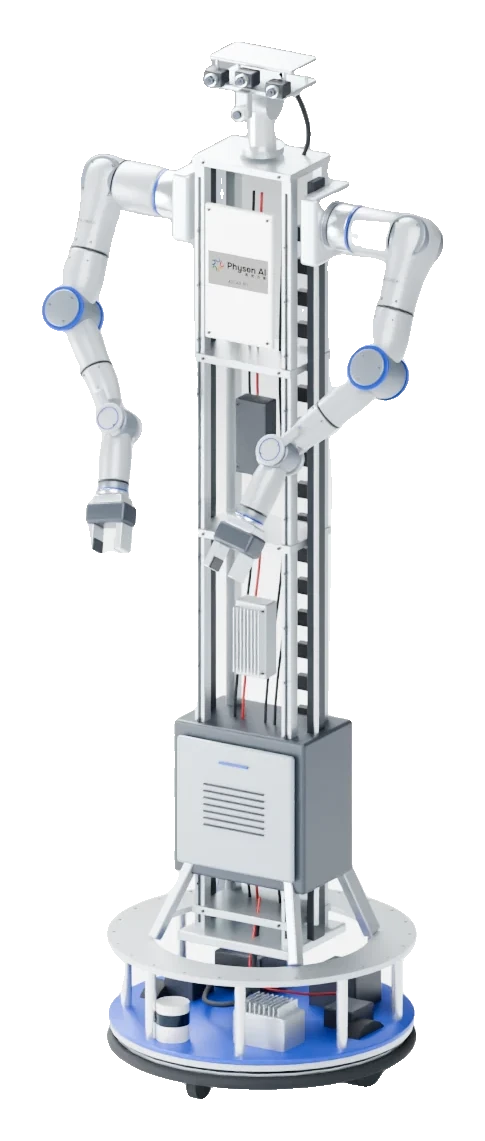
Robots and dexterous hands act in the real world. Ego cameras, grippers, gloves and armbands each capture a different layer of human demonstration.
A7 Dual-Arm Modular Research Platform
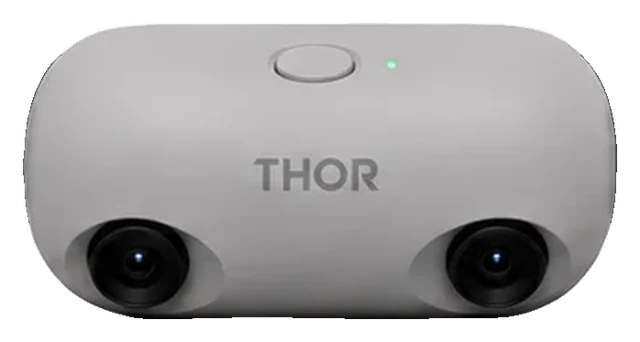
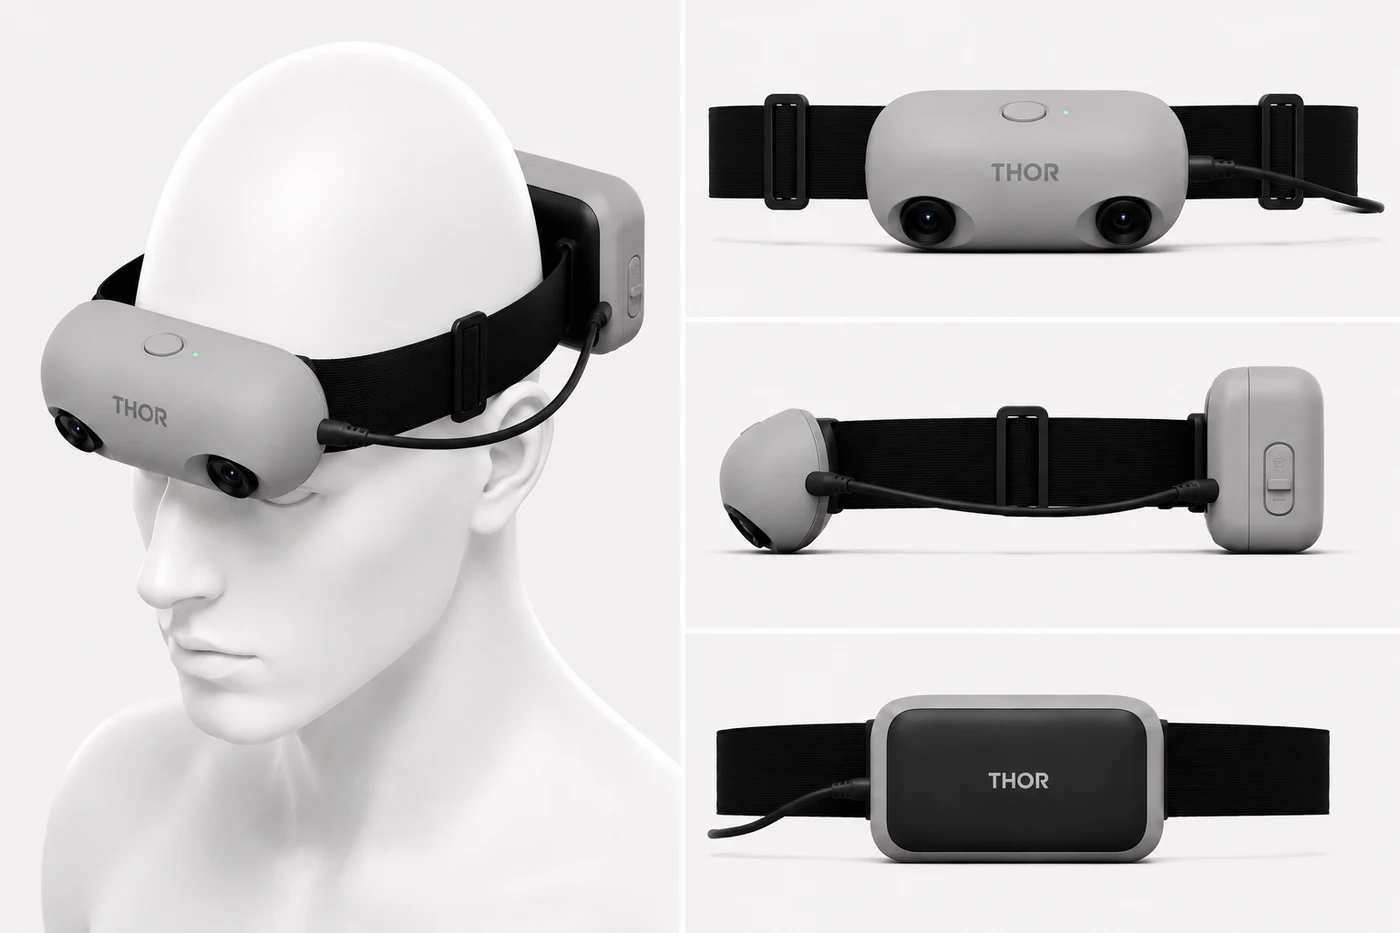 2 cameras + IMU
Stereo visual-inertial capture device
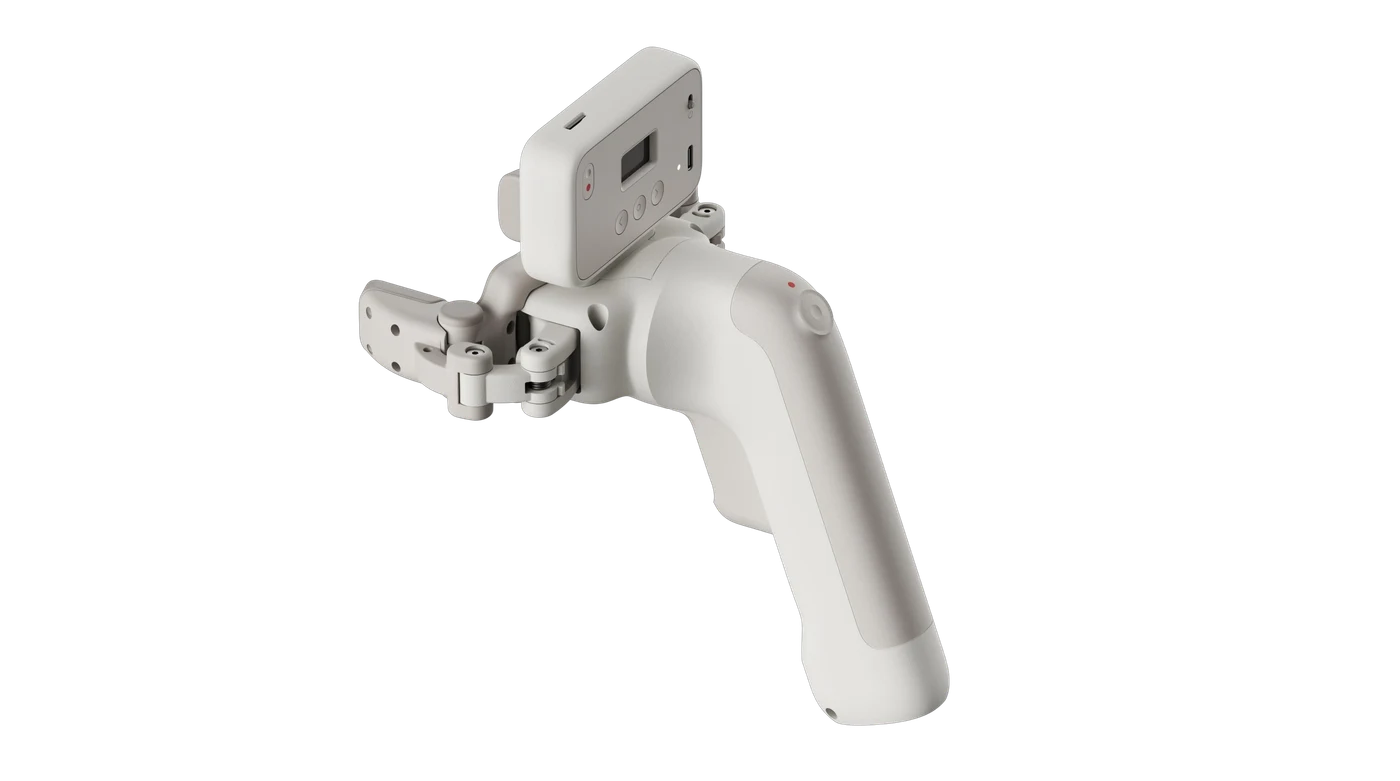 UMI Gripper
Handheld manipulation demonstration kit
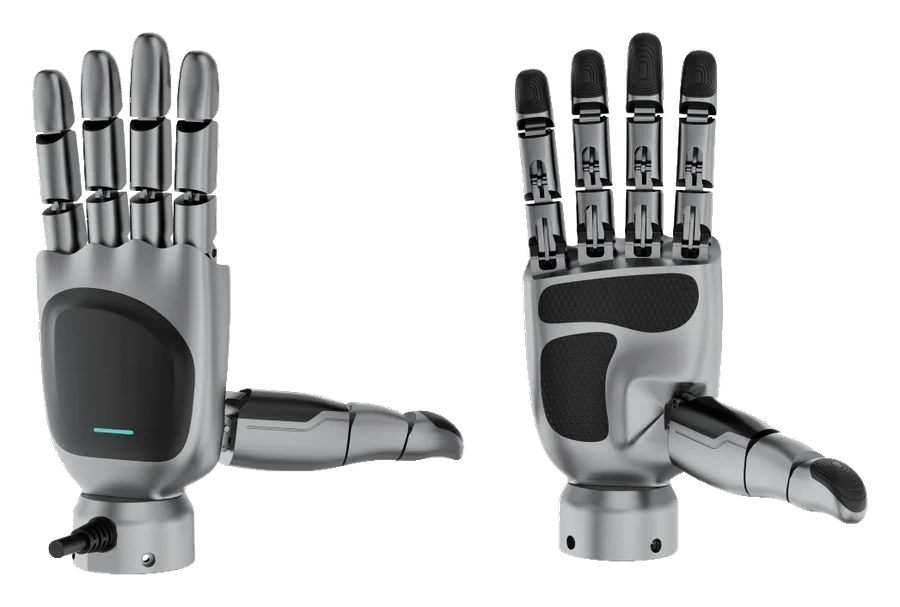
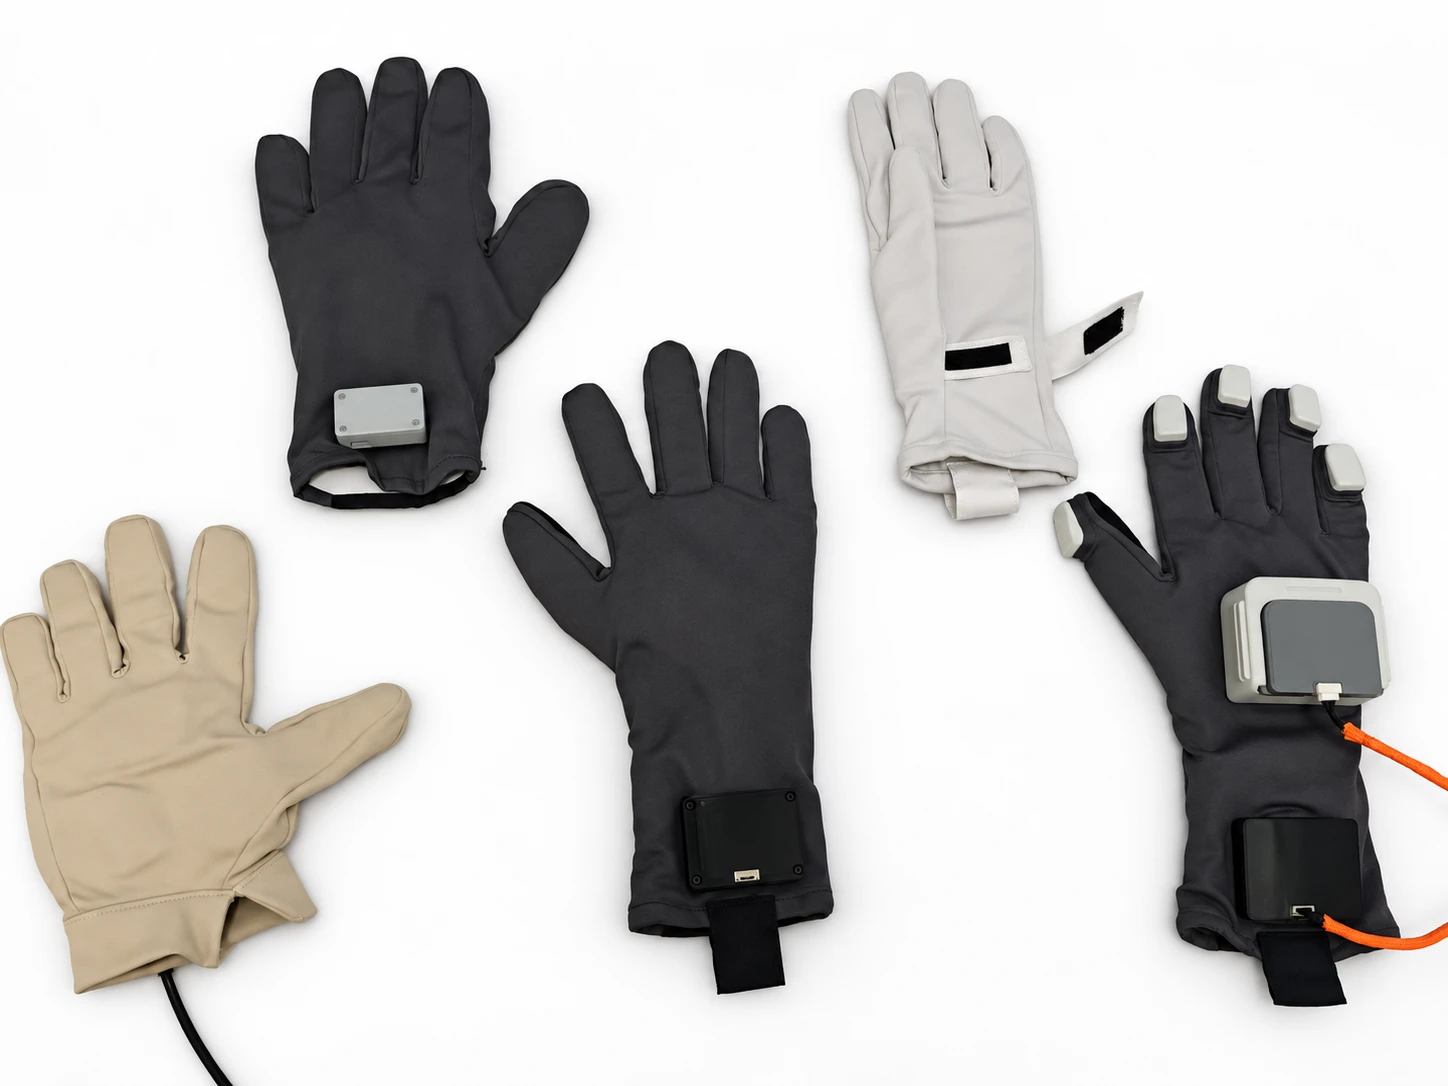 Tactile Data Glove
Tactile mapping with electromagnetic tracking
TRAIN ON YOUR TERMS
Capture workstations, on-robot inference and cloud training are planned separately. Size compute to your policy, data scale and deployment constraints, or plug into your existing environment.
A CLEAR PATH TO DELIVERY
From pilot to full delivery, every step has a clear deliverable and a sign-off.
Confirm the research question, existing equipment, data rights, timeline and acceptance criteria.
Validate equipment, synchronization, interfaces and baselines on a small batch or a single task.
Freeze the hardware and software scope, then deploy, capture or process data in batches.
Deliver the configuration, data and reports, then use failure records to plan the next round.
LET’S BUILD YOUR NEXT EXPERIMENT
Whether you're choosing devices, setting up a lab or running enterprise capture, start by telling us your goals and current setup.
Name, contact details and project needs are required. Everything else is optional.